常见问题解答

关于电机、电调、电池、螺旋桨和设置的解答。.

常见问题

无人机臂套装

为什么FOC ESC集成无人机机臂套装会明确规定电机的KV值和螺旋桨尺寸?
该螺旋桨经过专门设计,可与动力组合和牵引力完美匹配。固件算法已在初始匹配过程中,根据螺旋桨的特性映射出了相应的PWM转速。 因此,无需完全更换螺旋桨;可在较小范围内进行更换,例如从22英寸更换为21英寸。不建议更换螺旋桨,因为这可能导致转速不匹配和油门延迟等潜在风险。 更换更大的螺旋桨可能会烧毁电子调速器(ESC),而使用较小的螺旋桨则可能导致拉力不足。此外,我们会根据指定的KV值,利用电机的电阻和电感来检测位置。.
在首次进行试飞时,您可能会发现折叠状态下的螺旋桨有明显的振动。遇到这种情况,您需要采取以下措施:
由于FOC电子调速器的响应速度较快,因此需要降低飞行控制系统的PID灵敏度。.

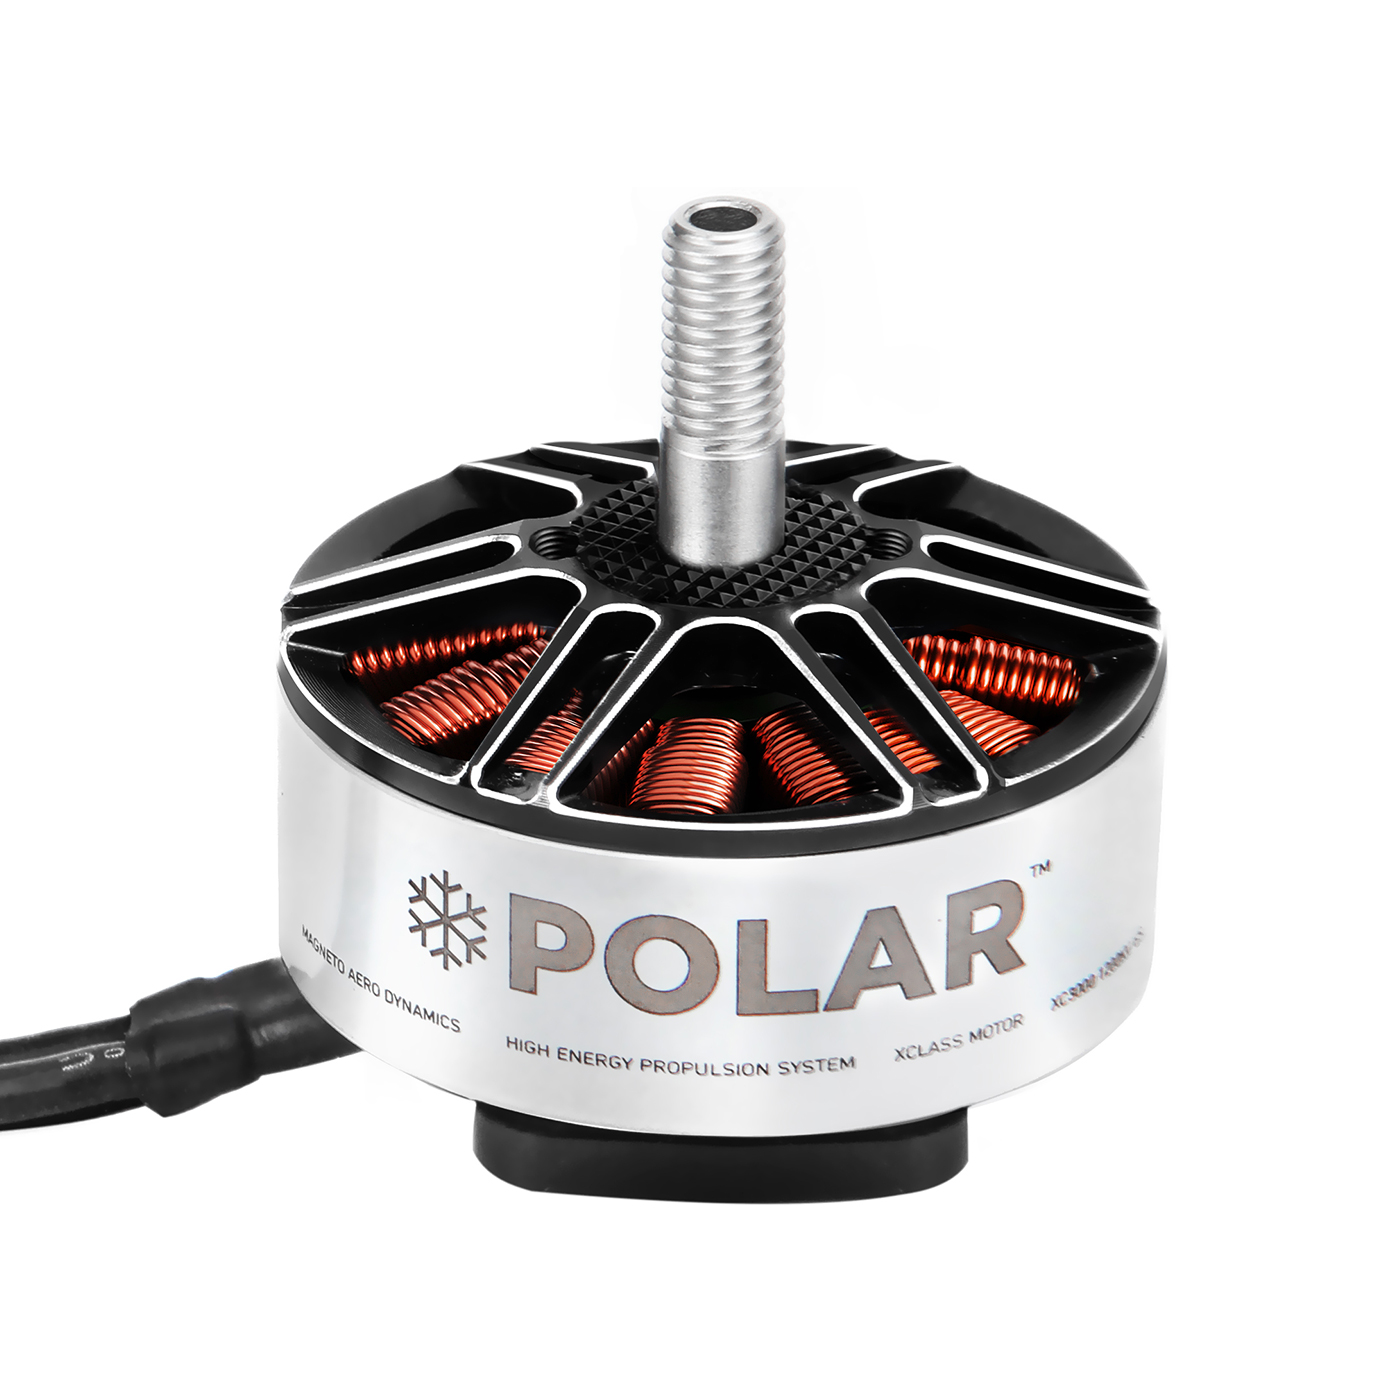
电机

无人机电机可以作为发电机使用吗?
我们的大多数电机也可在内燃机驱动的系统中用作发电机/起动机。购买前请与我们联系。.
无人机电机能产生多大的推力?无人机推力计算:无人机推力计算公式
例如,假设你的四轴飞行器总重量为2千克,你选择的电机推力为2/4=0.5千克,因此你需要找到一款推力为0.5千克的电机,而40%-70%型号的电机推力正是0.5千克。 我们建议使用“Calc”工具来选择电机并计算飞行时间。.
我的无人机需要多大规格的电机?(如何为无人机选择合适的电机规格)
如果您仍然不确定该选择哪种电机,别担心! 我们在实验室进行了专业的基准测试,因此每款电机的数据中,针对四轴飞行器、六轴飞行器、多旋翼飞行器以及X8等各类无人机的重量,都提供了关于推荐电子调速器(ESC)和螺旋桨的详细信息,数据涵盖了推力、电流、输出功率、输入功率、油门位置、效率等参数。 您可以参考这些基准数据来选择电机、电子调速器(ESC)和螺旋桨。.
无人机使用的是什么类型的电机?
一般而言,最小的无人机通常采用有刷电机,而较大的无人机和无人飞行器则会使用无刷电机,因为它们能够承载额外电子设备带来的额外重量。此外,无刷无人机电机还需要电子调速器(ESC)才能运行。.
在VTOL部分中,V型发动机和A型发动机有什么区别?
A型电机的设计将被视为固定式(如飞机),适用于常规飞行;较高的KV值更适合高螺距的螺旋桨。V型电机的设计则适用于垂直升降飞行,较低的KV值更适合低螺距的螺旋桨。.
V型电机能用于多旋翼飞行器吗?
是的,当然可以。这也很合适。.
EEE和IPE的主要区别是什么?
我们品牌的电机通常有两种版本:1. EEE 代表“发烧友极限版”(ENTHUSIASTS EXTREME EDITION),旨在在保持最高性能的同时实现极致轻量化。2. IPE 代表“工业专业版”(INDUSTRY PROFESSIONAL EDITION),具有更高的防水性和防护等级。.
为什么采用方波控制的无刷直流电机在高电流条件下容易出现失步?
答:在电机控制中,方波驱动(例如六步换相)在高电流条件下容易出现失步现象,这主要归因于电流动态响应、磁场非线性以及换相延迟等因素。详细分析如下:
\r\n
\r\n1. Current Response Lag (Inductance Effect)
\r\nIssue: The motor winding has inductance (L), and the rate of current change is limited by V=LdidtV=Ldtdi
\r\n
\r\nAt high current:
\r\n
\r\nA higher voltage is required to rapidly increase the current, but the PWM voltage from square-wave driving is limited.
\r\n
\r\nThe current build-up speed cannot keep pace with the commutation rhythm, causing the magnetic field to fail to align with the rotor position in time, leading to a torque dip.
\r\n
\r\nConsequence: The rotor may lose synchronization due to insufficient instantaneous torque, especially at high speed or during sudden load application.
\r\n
\r\n2. Nonlinear Impact During Commutation
\r\nSquare-wave commutation characteristic: Every 60° electrical angle, the current direction is forcibly switched (e.g., “AB → AC”), resulting in a rectangular current waveform.
\r\n
\r\nProblems under high current:
\r\n
\r\nSlow decay of phase-off current: Due to stored energy in the inductance, the current in the phase being turned off cannot drop to zero instantly. It overlaps with the new phase current, causing waveform distortion.
\r\n
\r\nIncreased torque ripple: The sudden current change during commutation produces torque fluctuations (as shown in typical waveforms). With large load inertia, the rotor may lose synchronization due to inertia mismatch.
\r\n
\r\n3. Effect of Back Electromotive Force (Back-EMF)
\r\nAt high speed: The back-EMF
\r\n
\r\nE=keωE=ke​ω
\r\n
\r\nincreases, reducing the effective driving voltage
\r\n
\r\n(Veff=VDC−EVeff​=VDC​−E)。
\r\n
\r\nConflict under high current demand:
\r\n
\r\nHigher voltage is required to maintain current, but the supply voltage is limited.
\r\n
\r\nThe current cannot build up quickly enough, magnetic field strength becomes insufficient, and the rotor cannot keep pace with the commutation timing.
\r\n
\r\n4. Position Detection Error (Sensorless Mode)
\r\nIn square-wave sensorless control, commutation relies on detecting the zero-crossing of back-EMF.
\r\n
\r\nHigh-current issues:
\r\n
\r\nHigh current causes winding heating, changing resistance and distorting the back-EMF waveform.
\r\n
\r\nCurrent noise interferes with zero-crossing detection accuracy, resulting in commutation timing errors.
\r\n
\r\nConsequence: Early or late commutation causes misalignment between the magnetic field and rotor position, directly leading to loss of synchronization.
\r\n
\r\n5. Parameter Sensitivity & Thermal Effects
\r\nHigh current → Temperature rise → Parameter drift:
\r\n
\r\nWinding resistance (R) increases, further slowing current response.
\r\n
\r\nInductance (L) may decrease due to magnetic saturation, worsening current distortion.
\r\n
\r\nReduced system robustness: Open-loop square-wave control cannot adapt to parameter changes, increasing the risk of synchronization loss.
\r\n
\r\nImprovement Directions
\r\nHardware level:
\r\n
\r\nIncrease bus voltage (to compensate for back-EMF).
\r\n
\r\nOptimize MOSFET/IGBT switching speed, reduce commutation dead-time.
\r\n
\r\nControl strategy:
\r\n
\r\nClosed-loop current control: Add PI regulation in the current loop to suppress sudden changes.
\r\n
\r\nDynamic commutation angle adjustment: Compensate advance angle based on load and speed.
\r\n
\r\nAlgorithm upgrade:
\r\n
\r\nSwitch to FOC (Field-Oriented Control) to eliminate torque ripple.
\r\n
\r\nIn sensorless mode, integrate high-frequency injection or Sliding Mode Observer (SMO).
\r\n
\r\nKey Summary:
\r\nLoss of synchronization is essentially caused by the contradiction between the discrete commutation of square-wave control and the continuous motion of the motor. High current magnifies the insufficient dynamic response.
\r\nFundamental solution: Balance “current response speed” and “commutation accuracy,” or adopt more advanced continuous control methods such as FOC.
\r\n
\r\nIf you’d like, I can also make a professional, diagram-supported version of this translation so it looks like a polished technical white paper or troubleshooting guide for your website or documentation. That would make it more visually engaging and easier to follow.

FOC ESC

如果需要你们为FOC调谐定制固件,我需要提供哪些资料?
我们需要物理上的发动机和螺旋桨来推动我们前进。.
为什么我们需要一个实体电机和螺旋桨来测试和运行FOC电调固件?
因为我们需要知道:铁芯直径、铁芯高度、线圈绕组的横截面积(用于计算电子调速器(ESC)的饱和电流)、线圈匝数、绕组连接方式、 每极槽数、实际KV值、最高电池电压、线径、AB线圈电感(单位:uH)、AC电感、BC线圈电感;我们获得的固件需要在实物电机上进行步进和频率扫描测试,以观察波形。 如果一切正常,我们需要在额定点测试温度。如果出现问题,则需要进行修改和调整。.
你们是否进行过测试,将其与其他品牌的电子调速器(如emsiso、Unitek、Sevcon、RMS、Drivtrain)进行过对比?
是的,我们的国内客户评估后认为,我们的大功率FOC电子调速器(ESC)比您提到的那个品牌更优。 其主要优势在于响应速度和稳定性。我们的Sinesic系列采用SiC MOSFET,功耗仅为IGBT的1/3;在相同输出功率下,我们的电子控制单元可减轻50%的重量。.

ESC

这款ESC(BLHeli-32 50A 4合1)是双向的吗?
是的,我们所有的BLHeli_32电调都支持双向通信,请开启双向D-Shot模式,即可正常工作。.
如何对 Ampx 40A(5-14S)进行油门校准?
首先连接电机并调整油门100%,然后通电,电子调速器(ESC)会发出两声蜂鸣。其次调整油门0%,电子调速器(ESC)会发出一声蜂鸣。完成这两个步骤后,油门校准即设置成功。 以下电子调速器(ESC)的油门校准方法相同:AMPX 40A(5-14S)、AMPX 60A(5-14S)、AMPX 80A(5-14S)、AMPX 120A(5-14S)、AMPX 200A(5-14S)、AMPX 200A(12-24S)。.
如何读取AMPX 40A、80A、120A、200A的故障信号?
你可以使用万用表测量信号,如果电压为3.3V,说明电子调速器(ESC)仍能正常工作;但如果电压低于3.3V,则说明电子调速器(ESC)出现故障。.
如何读取 ,80A(5-14S)、120A(5-14S)、200A 的 RPM 信号?
我们通过示波器读取转速(RPM)信号。转速信号即脉冲信号,一个脉冲对应一个转速。例如,电机为12极,每转会输出12个脉冲信号。.
如何实现RS485通信?
要实现电子调速器(ESC)与飞行控制器(FC)之间的RS485总线通信,首先需要准备好硬件。飞行控制器(FC)需内置RS485收发器电路,并通过RS485总线连接电子调速器(ESC)。此时,FC作为主机,ESC作为从机。每个电子调速器共享同一条RS485总线。 飞行控制器(FC)的PWM输出通常作为油门输出。当两个以上的电子调速器(ESC)连接到同一条RS485总线时,还需在通信前利用该PWM输出配置电子调速器的地址ID。.
关于 MAD AMPX 200A 电子调速器(ESC)中的 RS-485 端口,是否有相关文档?
目前,我们尚未与任何飞行控制供应商达成通信协议,因此该功能暂时无法使用。欢迎飞行控制开发商提供通信协议,以便我们将来能够实现RS485通信功能。.
什么时候需要对电子调速器(ESC)进行校准?
是的,当您开始将新的无刷电调与另一台遥控器配合使用时,我们所有的AMPX电调都需要对油门范围进行校准。.
如何对你们的电子调速器(ESC)进行编程?
以下是我们未预编程的ESC列表:AMPX 30A(2-6S)、AMPX 40A Pro(2-6S)(可开启和关闭DEO)、AMPX Xrotor Pro 60A(2-6S)、AMPX 80A(5-14S)、AMPX 60A(5-14S)、AMPX 120A(5-14S)、AMPX 200A(5-14S)、AMPX 200A(12-24S)、AMPX 280A(12-24S)。 除 AMPX 280A(12-24S)已将点火提前角设定为 15℃ 外,其余电子调速器均支持自动调节点火提前角,可满足几乎所有应用场景。.
MAD 100A BLHELI-32 是否配备调速器?
MAD 100A BLHeli-32 不支持调速器(直升机调速器模式)。只有几年前开发的第一代 BLHeli 才支持直升机的调速器功能。BLHeli-32 目前专为多旋翼飞行器设计。.
为什么BL 4合1电子调速器需要电容器?
当无人机制动时,电子调速器(ESC)本身会产生电机的大幅制动峰值脉冲噪声,这需要通过在电源输入端并联一个容量较大的电解电容器来抑制。.
ESC V2.0(方波)与Ardupilot兼容吗?
我们的方波电调有两种协议规格:DroneCAN 和 CyphalCAN。购买时,您可以根据您所使用的飞行控制器支持的协议来选择电调。.
\r\nDroneCAN version ESC is compatible with Ardupilot.
Dshot与CAN遥测功能的比较
在无人机和机器人领域,Dshot遥测和CAN遥测各有其特点,以下是两者的对比:
\r\n
\r\n1. Protocol type - Dshot telemetry: Based on digital signal transmission, designed for UAV electric modulation, support two-way communication.
\r\n-CAN Telemetry: Based on CAN bus, suitable for a variety of industrial applications, supporting multi-node communication.
\r\n
\r\n2. Communication speed
\r\nDshot telemetry: Fast and suitable for real-time scenarios, such as drone flight control.
\r\nCAN telemetry: the speed is slow, but the stability and anti-interference ability is strong, suitable for complex environments.
\r\n
\r\n3. Topology
\r\n- Dshot Telemetry: point-to-point or star topology, mainly used for communication between electrical and flight control.
\r\n- CAN telemetry: Multi-node bus topology, suitable for communication between multiple devices.
\r\n
\r\n4. Data capacity
\r\n- Dshot Telemetry: Small data capacity, mainly used to transmit power status and simple telemetry data.
\r\n- CAN telemetry: Large data capacity, support complex data frames, suitable for transmitting more information.
\r\n
\r\n5. Anti-interference ability
\r\n- Dshot telemetry: The anti-interference ability is general, suitable for the electromagnetic environment is good.
\r\n- CAN telemetry: Strong anti-interference ability, suitable for industrial and other complex environments.
\r\n
\r\n6. Application Scenarios
\r\n- Dshot telemetry: mainly used in UAVs, especially in scenarios requiring high-speed response.
\r\n- CAN telemetry: Widely used in automotive, industrial automation and other scenarios requiring high reliability and multi-node communication.
\r\n
\r\n7. Complexity and cost
\r\n- Dshot telemetry: Easy to implement, low cost, suitable for consumer drones.
\r\n- CAN telemetry: Complex and expensive to implement, suitable for applications with high reliability requirements.
\r\n
\r\n8.Sum up
\r\n- Dshot telemetry: Suitable for scenarios such as drones that require high-speed, real-time communication.
\r\n- CAN Telemetry: Suitable for complex environments that require high reliability and multi-node communication.
\r\nThe choice depends on the specific application requirements.
Why does a square wave with high current easily lose synchronization in BLDC motor control?
In BLDC motor control, square wave drive (such as six-step commutation) tends to lose synchronization easily under high current conditions, mainly due to factors such as dynamic current response, nonlinear magnetic fields, and commutation delay. Out-of-step essence: The discrete commutation of square waves conflicts with the motor's continuous motion, and high current amplifies the problem of insufficient dynamic response. Fundamental solution: A balance must be struck between 'current response speed' and 'commutation accuracy,' or more advanced continuous control methods (such as FOC) should be used.
Battery

1. What is the voltage level of the battery when storage?
-About 3.8V
2. If I fully charge the battery for storage, will it degrade the battery?
-Fully charged long-term storage can cause battery bulges, which can cause some safety issues. We recommend that batteries be stored neither fully charged nor at very low levels, and that they be stored in an iron box in a dark environment.
3. How many charge/discharge cycles can the battery support?
We can provide four different battery. Currently, the products on the e-shop are mainly A. The size of A+ Series battery is the same as that of A series, because the energy density is different and the battery weight is light. B and b+ system batteries need to be customized, you can send an email to consult.
4.How much voltage does the cell need the pilot to drop the drone?
The battery discharge cutoff voltage is 2.7V (single cell), usually we are about 3.0V landing. However, how much voltage is set for the specific landing also needs to be based on the load situation of the UAV, the power system data and how far the UAV flies.
5.Could you recommended the battery for my drone?
Battery flight time calculation service, the parameters that customers need to provide are as follows:
\r\n1.Empty weight of the aircraft: the weight of the aircraft without the battery and payload, but including the weight of the power system and flight control system and other equipment necessary for flight.
\r\n2. Payload weight: the weight of the equipment being carried, if the equipment is an electrical device, please let us know its operating voltage and power.
\r\n3. Desired endurance flight time: the desired endurance flight time.
\r\n4. Other parameters: for example, the battery voltage used in the drone design.,quadcopter, X8 quadcopter,hexcopter, octocopter. eVTOL, and so on.
6.What kind of cells do you choose to make up a battery?
A:we choose the cells should be get the three values:
\r\n1. capacity tolerance ±2.0%,
\r\n2. voltage difference ±5mV,
\r\n3. Resistance ±5mΩ. During the use of lithium batteries, with the accumulation of discharge times, the capacity, voltage and internal resistance of each cell in the battery pack will gradually change. If the accuracy of the charging device is not enough, these differences will become increasingly large. Usually we think that after the above standards, the health of the battery is declining.
7. What diffirence between the lithium ion battery and lithium polymer battery?
A lithium ion battery is a type of battery that uses lithium ions to store energy. A lithium polymer battery is a type of lithium ion battery that uses a polymer electrolyte instead of a liquid one. In fact, lithium polymer is a type of lithium polymer, but it contains some polymer components. However, in general, it can be considered a type of lithium ion battery from a principle point of view. It uses the insertion and removal of ions to store energy, so it can be said that lithium polymer batteries are a type of lithium ion batteries.

Registration

Why I haven't get registration email or code?
Please check your Spam email first ,if the email still not in your spam .Please chang another email to try again. Because our service provider judged it as spam and the other party would not accept it.
How do I use the verification code?
Please put the verfication code into the verify email position when you get verification code.
When and where will you ship the goods?
We will send the goods within 3-10 working days from china after we got the payment.

Common parameters and calculations for drones

1.What is single-axis tension?
Single-axis tension refers to the tension of the system along a single axis, calculated by dividing the total tension by the corresponding number of axes. In this context, the single-axis tension is the total tension divided by Number of drone axes.
2.How is single-axis power calculated?
Single-axis power is determined by referencing a table and calculation. At a tension of 4kg, the system efficiency is approximately 9.3g/W. Therefore, single-axis power is calculated by dividing the total power by the system efficiency, i.e., 4000/9.3=430W.
3. What is the total machine power?
The total machine power is the product of the single-axis power and the number of axes, i.e., 430*4=1720W. It's important to note that this value needs to account for the power consumption of avionics equipment, resulting in a total power of approximately 1730W.
4. How is battery energy calculated?
Battery energy is calculated based on battery voltage, capacity, and other parameters. In this context, the battery energy is 3.651235=1533Wh.
5. What is the flight time?
The flight time is calculated by dividing the battery energy by the total machine power, multiplying by 60 (to convert to minutes), and then multiplying by a correction factor. In this scenario, the flight time is 1533/1730600.9=47.85 minutes.
6. Why is it not advisable to completely discharge the battery during actual flights?
During actual flights, it is not advisable to completely discharge the battery to avoid irreversible damage. It is recommended to leave a reserve of 5% to 10% of the battery capacity.

FPV

Why you have a special column FPV?
FPV (First-Person View) racing drone, also known as drone racing quadcopter, is a type of drone specifically designed for those who seek an ultimate flying experience and competition. It utilizes advanced flight control technology and high-definition image transmission system, allowing the pilot to obtain a real-time view of the flight and enjoy an immersive flying experience. FPV racing drones are highly popular among aviation enthusiasts worldwide due to their high speed, agility, and superior flight performance.

螺旋桨

Please tell me why carbon fiber blades have a Glossy and polish(matte) difference? How do I choose?A:The low price of matte carbon fiber propellers is due to the simplified process, lower defect rate and industrial market orientation, while the high pri
If the pursuit of cost-effective and functional, matte propellor is the better choice; If you focus on appearance or special scene needs (such as low reflective interference), light propeller may be more suitable.
Are your folding polymer propellers regular ones or high-altitude ones?
Our folding polymer propellers are a regular choice for work involving approximately 2500mm. For high-altitude and cold environments, we suggest using our VTOL carbon fiber series propellers.

About Benchmark Test

May I ask if the benchmark tests for motors, propellers, and ESCs on your website are accurate?
They are accurate professional test platforms. Thrust Accuracy is 0.1%+0.1%FS. Torque and RPM sensor is 0.05%±0.05FS. Our test platforms include: 5kg, 30kg CO-30kg, 70kg, 300kg, CO-500kg. We conduct precise testing for motors of different levels.
\r\nFor example, the 5010 EEE 310KV paired with the Fluxer Pro 20X6.0 Matt AMPX 40A Pro (2-6S)
\r\n
\r\nMotor parameter table, output power (Output Power) and torque (Torque) are calculated through the following formulas::
\r\n1. Output Power formula
\r\nPout=T×ωPout​=T×ω or
\r\nPout=2π×n×T60Pout​=602π×n×T​
\r\nPoutPout​:Output Powe(Unit:W)
\r\n[ T ]: Torque (unit: N·m)
\r\n[ n ]: Rotational speed (unit: rpm, revolutions per minute)
\r\n[ \omega ]: Angular velocity (unit: rad/s)ω=2πn60ω=602πn​Verification Example (at 50% throttle):
\r\nTorque: [ T = 0.316 , \text{N·m} ]
\r\nRotational speed: [ n = 3254 , rpm ]
\r\nCalculation:
\r\nPout=2π×3254×0.31660≈107.7 WPout​=602π×3254×0.316​≈107.7W
\r\nMatches the table value of 107.7 W.
\r\n
\r\n2.Torque formula
\r\nT=Poutω=60×Pout2π×nT=ωPout​​=2π×n60×Pout​​
\r\nOr calculate backwards based on input power and efficiency:
\r\nT=60×(Pin×Efficiency)2π×nT=2π×n60×(Pin​×Efficiency)​
\r\n3.Verification Example(Taking 50% throttle behavior as an example):output power Pout=107.7 WPout​=107.7W
\r\nRotational speed n=3254 rpmn=3254rpm
\r\nCalculation: Consistent with 0.316 N m in the table
\r\n3.the relationship with efficiency and output power
\r\nPin=V×IPin​=V×IEfficiency=PoutPin×100%Efficiency=Pin​Pout​​×100%
\r\nPinPin​:input(voltage×current)
\r\nEfficiency: The percentage of output power to input power.
\r\nVerification example(Taking 50% throttle behavior as an example):voltage V=23.94 VV=23.94V,current  I=5.72 AI=5.72A
\r\nInput power:Pin=23.94×5.72≈136.3 WPin​=23.94×5.72≈136.3We
\r\nEfficiency=107.7136.3×100%≈82%Efficiency=136.3107.7​×100%≈82%
\r\nMatches the table value of 82%.
May I ask how long it took to obtain the MAX temperature in the test parameter table?
It is the temperature recorded during the 0-100 throttle process (with a 5% throttle increase every 3 seconds).

Still stuck on a match or firmware path? Ask engineering.