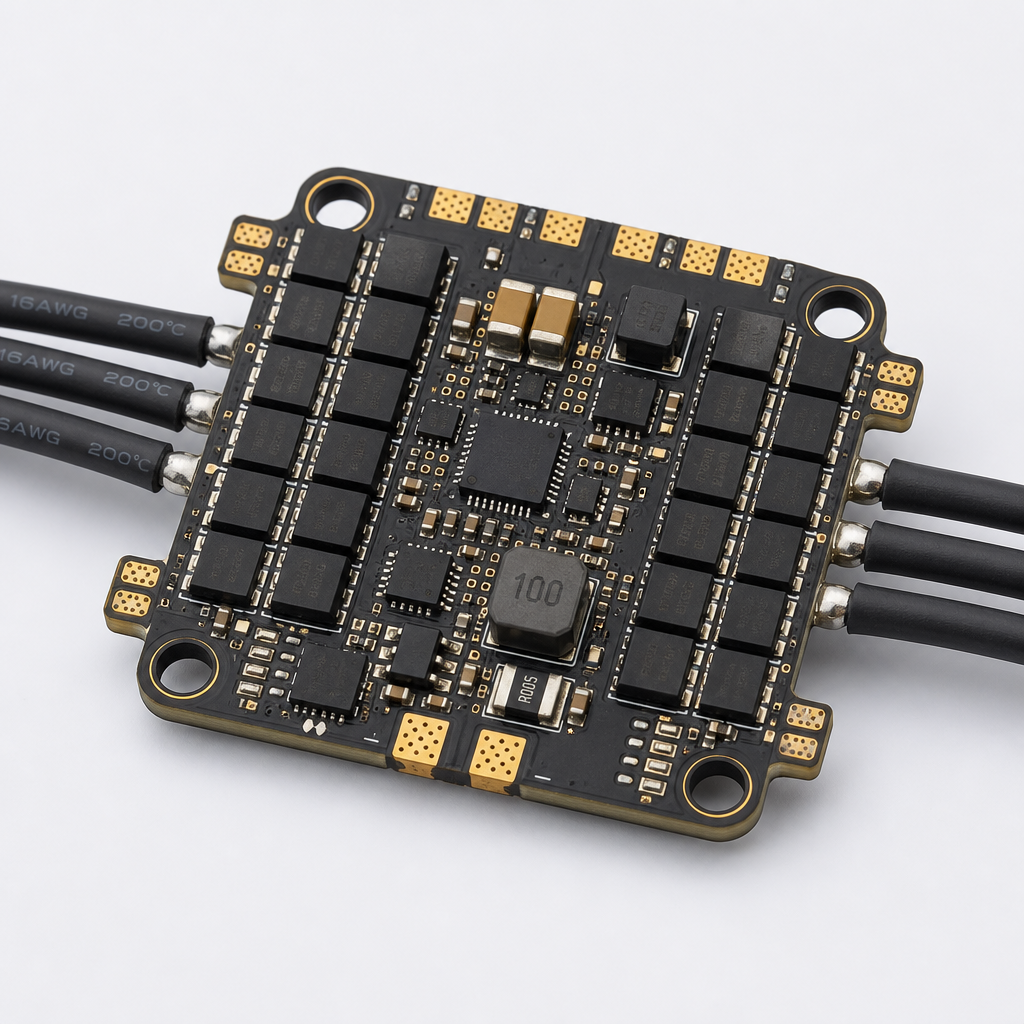
is this ESC(BLHeli-32 50A 4in 1) bidirectional?
Yes, all our BLHeli_32 ESC is support bidirection, please open the bidirection Dshot, it will work.
how to do the throttle calibration of the Ampx 40A(5-14S)?
First connect motor and adjust throttle100%, then power on and ESC will beep two times. Second adjust throttle 0% and ESC will beep one time. After finishing these two steps, throttle calibration will be set successful. The followings ESC are taken the same way to do the throttle calibration: AMPX 40A(5-14S), AMPX 60A(5-14S), AMPX 80A(5-14S),AMPX 120A(5-14S),AMPX 200A(5-14S),AMPX 200A(12-24S).
How to read the error signal of AMPX 40A, 80A,120A,200A?
You can use a multimeter to measure the signal, if the voltage is 3.3V means the ESC is still good. but the voltage under 3.3V mean the ESC is error.
How to read the RPM signal of ,80A(5-14S),120A(5-14S),200A?
We read the RPM signal by oscilloscope . RPM signal=pulse signal, an electrical speed corresponds to a pulse. for example, the motor is 12 poles, each revolution have 12 pulse signal output.
How to realize RS485 communication?
To relize ESC RS485 bus communication with flight controller, the hardware should be preparated first,The Flight Controller(FC) need to contain a RS485 Transceiver circuit, Connecting ESC via RS485 bus. FC as host, ESC as Device. Each ESC shares the same RS485 bus. FC’s PWM output as Throttle output as usual. Also using the PWM output to configure ESC Address ID before communication when more than two ESCs connecting the same RS485 bus.
Is there any documentation for the RS-485 port in the MAD AMPX 200A ESC?
So far we have not reached a communication agreement with any flight control supplier at present,so this function is not available at present. Welcome flight control developers to provide communication protocol so that we can achieve RS485 communication function in the future.
When I need to do Calibration of ESC?
Yes, All of our AMPX ESC need to do calibration the throttle range when you start to use a new brushless ESC with another transmitter.
How can I program your ESC?
Here is list of our ESC which is not be propramed:AMPX 30A(2-6S), AMPX 40A pro(2-6S) ( it can open and close the DEO),AMPX xrotor pro 60A(2-6S),AMPX 80A(5-14S),AMPX 60A (5-14S),AMPX 120A (5-14S),AMPX 200A (5-14S),AMPX200A(12-24S),AMPX280A(12-24S). Except the AMPX 280A(12-24S) had set the timing degree is 15℃. other ESC is auto-adjusting timing meet almost all application.
Does the MAD 100A BLHELI-32 have Governor?
The MAD 100A BLHeli-32 does not support Governor (helicopter governor mode). Only the first generation of BLHeli, developed several years ago, had support for the helicopter's GOVERNOR function. BLHeli-32 is now exclusively designed for multirotors.
Why does BL 4in1 ESC need a capacitor?
When the drone braking, the ESC itself will produce a large brake peak pulse noise of the motor, which needs to be suppressed by a relatively large capacity electrolytic capacitor in parallel at the input end of the power supply.
Is the ESC V2.0( square wave) compatible with Ardupilot?
Our square-wave ESC has two versions of protocol specifications: DroneCAN and CyphalCAN. When purchasing, you can choose the ESC based on the protocol supported by your own flight controller.
DroneCAN version ESC is compatible with Ardupilot.
Comparison of the telemetry function of Dshot and CAN
Dshot telemetry and CAN telemetry have their own characteristics in the field of drones and robots, and here is how they compare:
1. Protocol type - Dshot telemetry: Based on digital signal transmission, designed for UAV electric modulation, support two-way communication.
-CAN Telemetry: Based on CAN bus, suitable for a variety of industrial applications, supporting multi-node communication.
2. Communication speed
Dshot telemetry: Fast and suitable for real-time scenarios, such as drone flight control.
CAN telemetry: the speed is slow, but the stability and anti-interference ability is strong, suitable for complex environments.
3. Topology
- Dshot Telemetry: point-to-point or star topology, mainly used for communication between electrical and flight control.
- CAN telemetry: Multi-node bus topology, suitable for communication between multiple devices.
4. Data capacity
- Dshot Telemetry: Small data capacity, mainly used to transmit power status and simple telemetry data.
- CAN telemetry: Large data capacity, support complex data frames, suitable for transmitting more information.
5. Anti-interference ability
- Dshot telemetry: The anti-interference ability is general, suitable for the electromagnetic environment is good.
- CAN telemetry: Strong anti-interference ability, suitable for industrial and other complex environments.
6. Application Scenarios
- Dshot telemetry: mainly used in UAVs, especially in scenarios requiring high-speed response.
- CAN telemetry: Widely used in automotive, industrial automation and other scenarios requiring high reliability and multi-node communication.
7. Complexity and cost
- Dshot telemetry: Easy to implement, low cost, suitable for consumer drones.
- CAN telemetry: Complex and expensive to implement, suitable for applications with high reliability requirements.
8.Sum up
- Dshot telemetry: Suitable for scenarios such as drones that require high-speed, real-time communication.
- CAN Telemetry: Suitable for complex environments that require high reliability and multi-node communication.
The choice depends on the specific application requirements.
Why does a square wave with high current easily lose synchronization in BLDC motor control?
In BLDC motor control, square wave drive (such as six-step commutation) tends to lose synchronization easily under high current conditions, mainly due to factors such as dynamic current response, nonlinear magnetic fields, and commutation delay. Out-of-step essence: The discrete commutation of square waves conflicts with the motor's continuous motion, and high current amplifies the problem of insufficient dynamic response. Fundamental solution: A balance must be struck between 'current response speed' and 'commutation accuracy,' or more advanced continuous control methods (such as FOC) should be used.