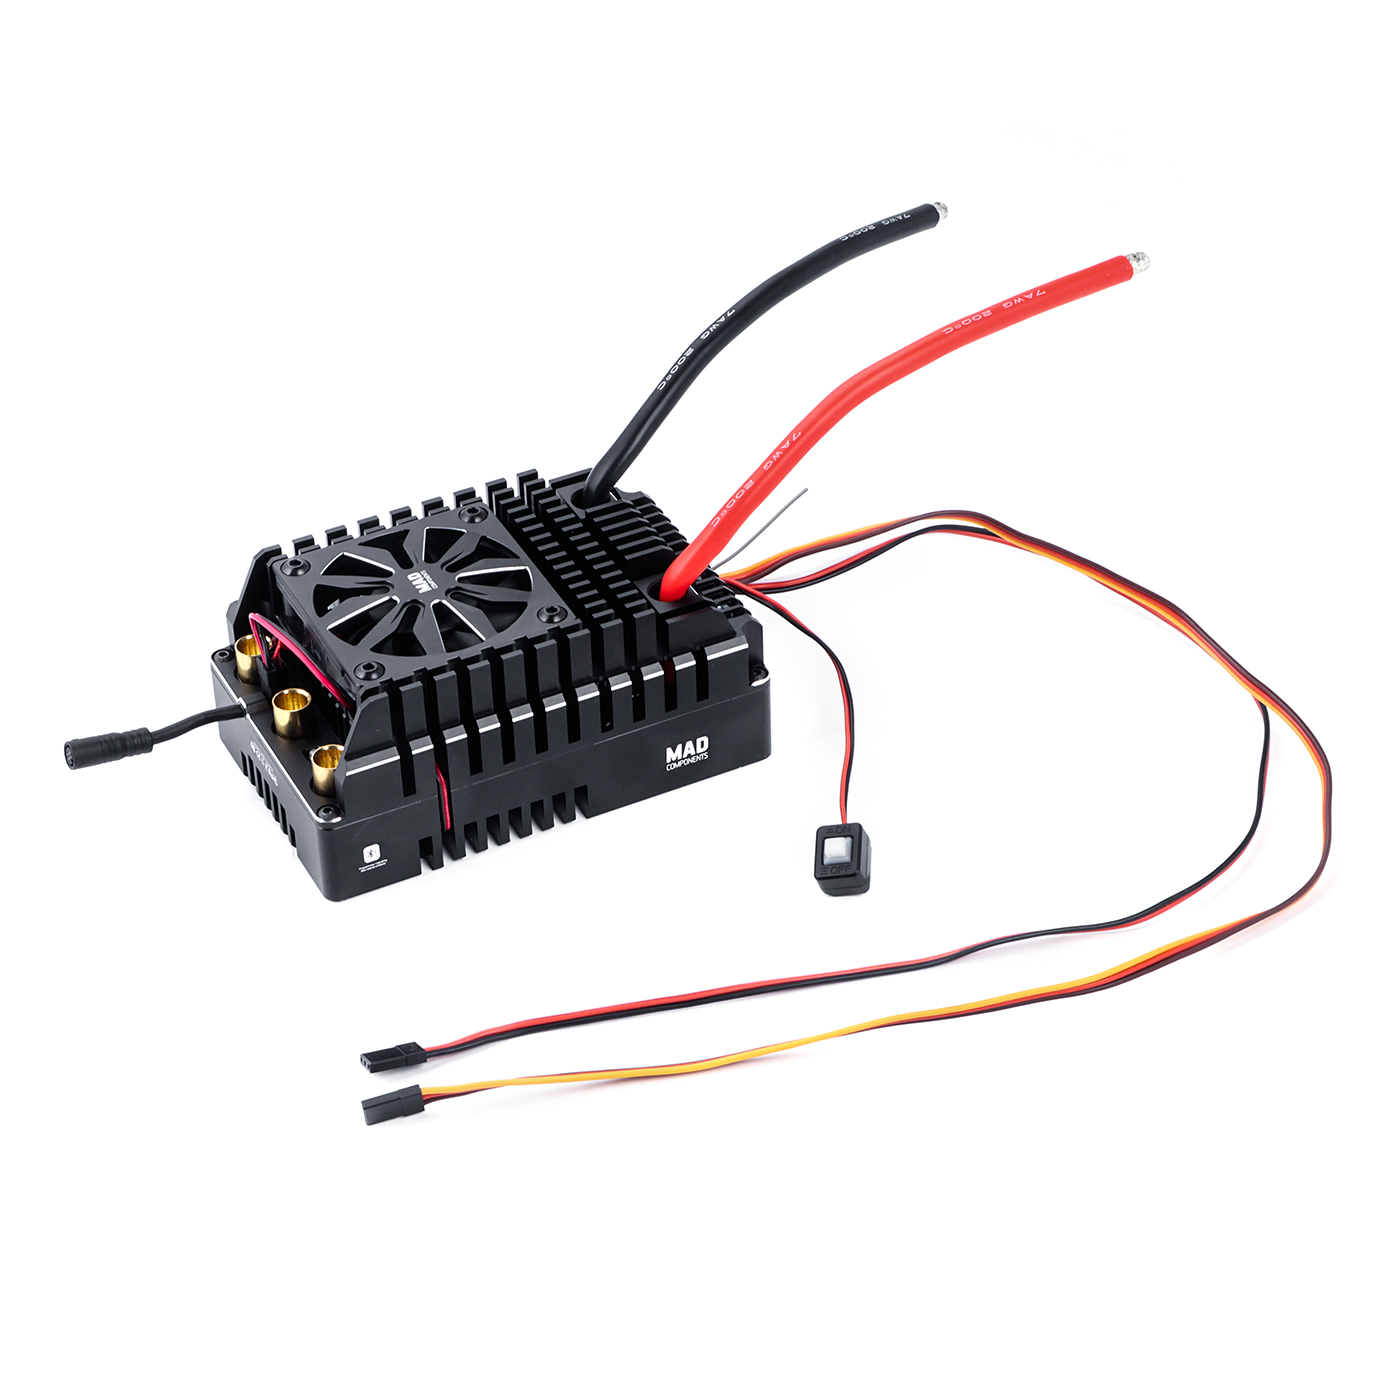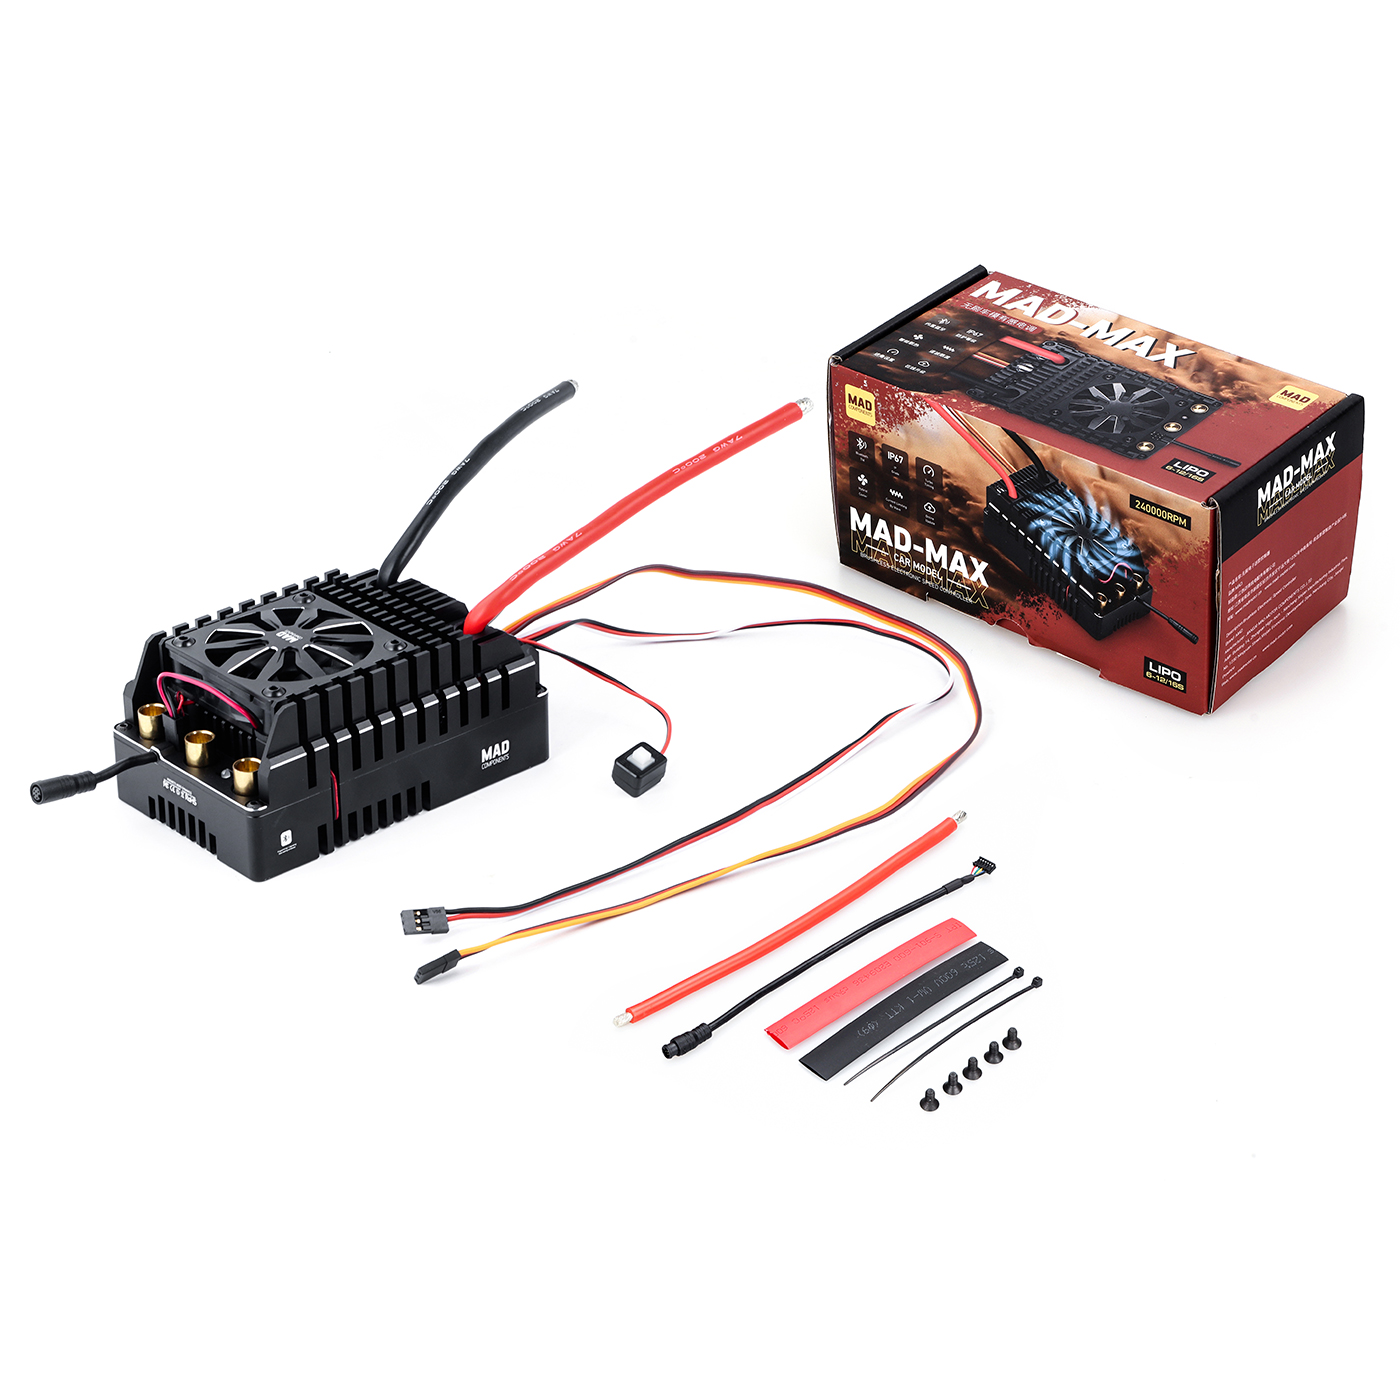


Product Specifications:
| Item | Description | |
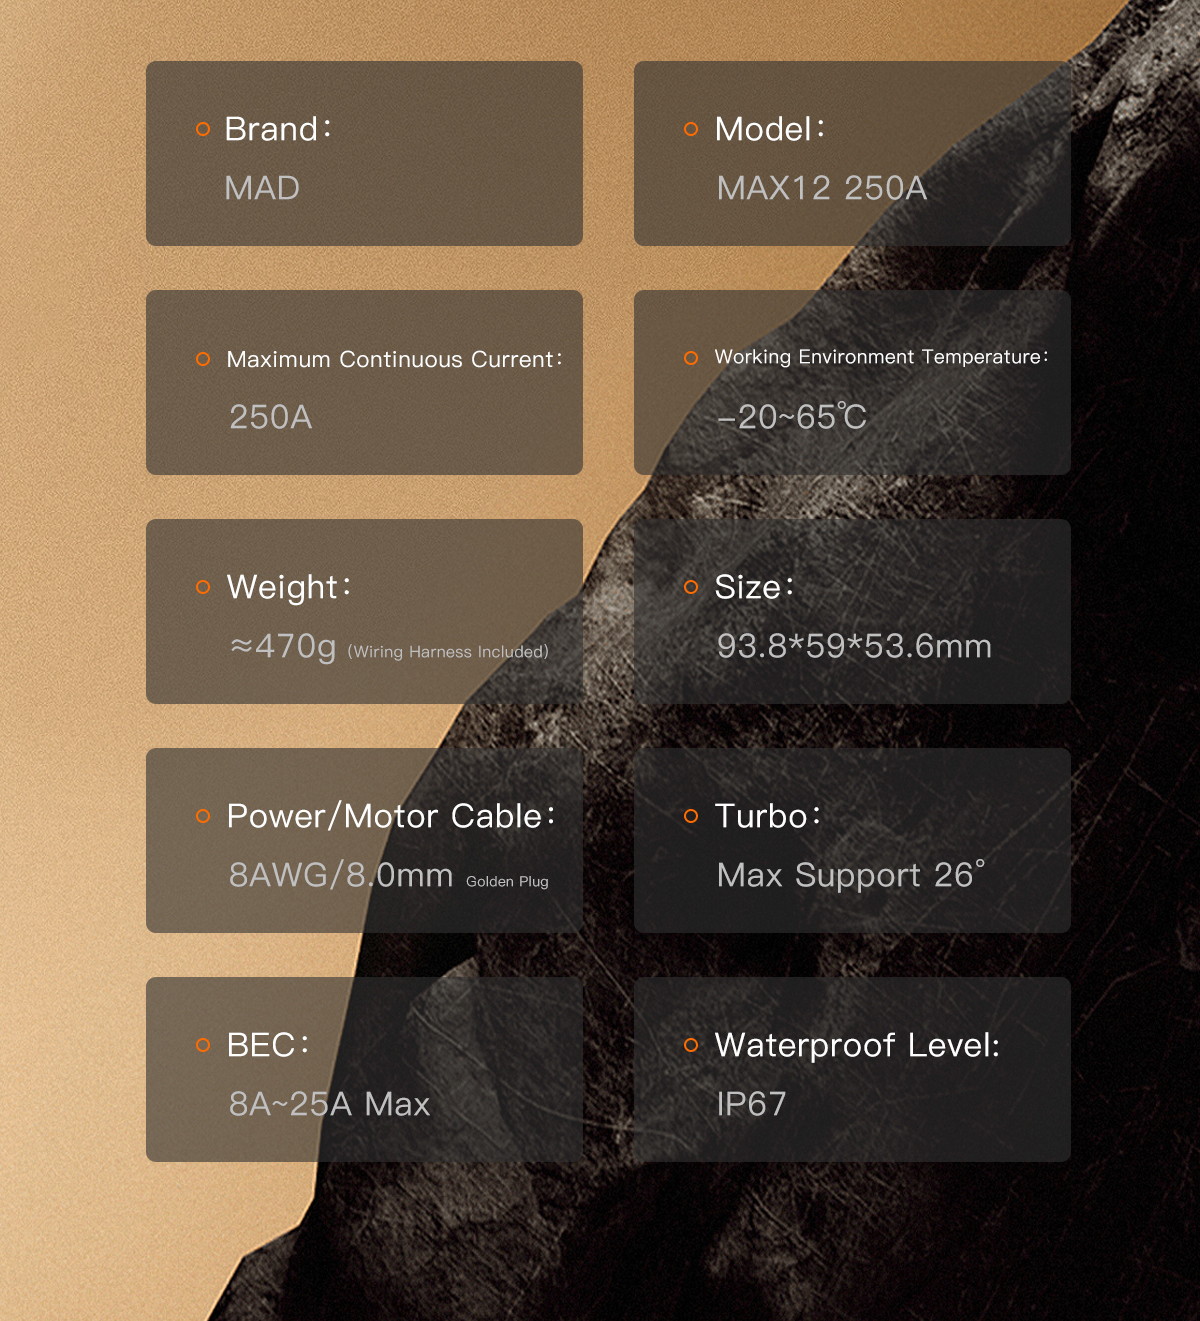
| Current | 250A Continuous Current | Current control is similar to wave-by-wave current limiting which effectively limit peak current to avoid motor damage. |
| Power supply | 6~12S LiPo | When using DC power supply instead of pure battery supply, its discharge and the power recovery capability must be considered. If the power supply capacity is limited, the operating parameters (such as acceleration and corresponding braking options, etc.) can be appropriately modulated. |
| Recommended motor | Sensor or sensorless square wave control of brushless motors |
|
| Motor speed | When the number of pole pairs is 1, the electrical speed is exactly equal to the mechanical speed. Others: Electrical speed = Mechanical speed × Number of pole pairs = KV value × Bus voltage × Number of pole pairs Note: max electric speed 240,000rpm. |
Speed of the motor is very high when idling. Stay safe. |
| BEC | Voltage: 6.0V/7.4V/8.4V, it can be switched through the mobile APP. Current: 8A continuously, 25A short-term |
|
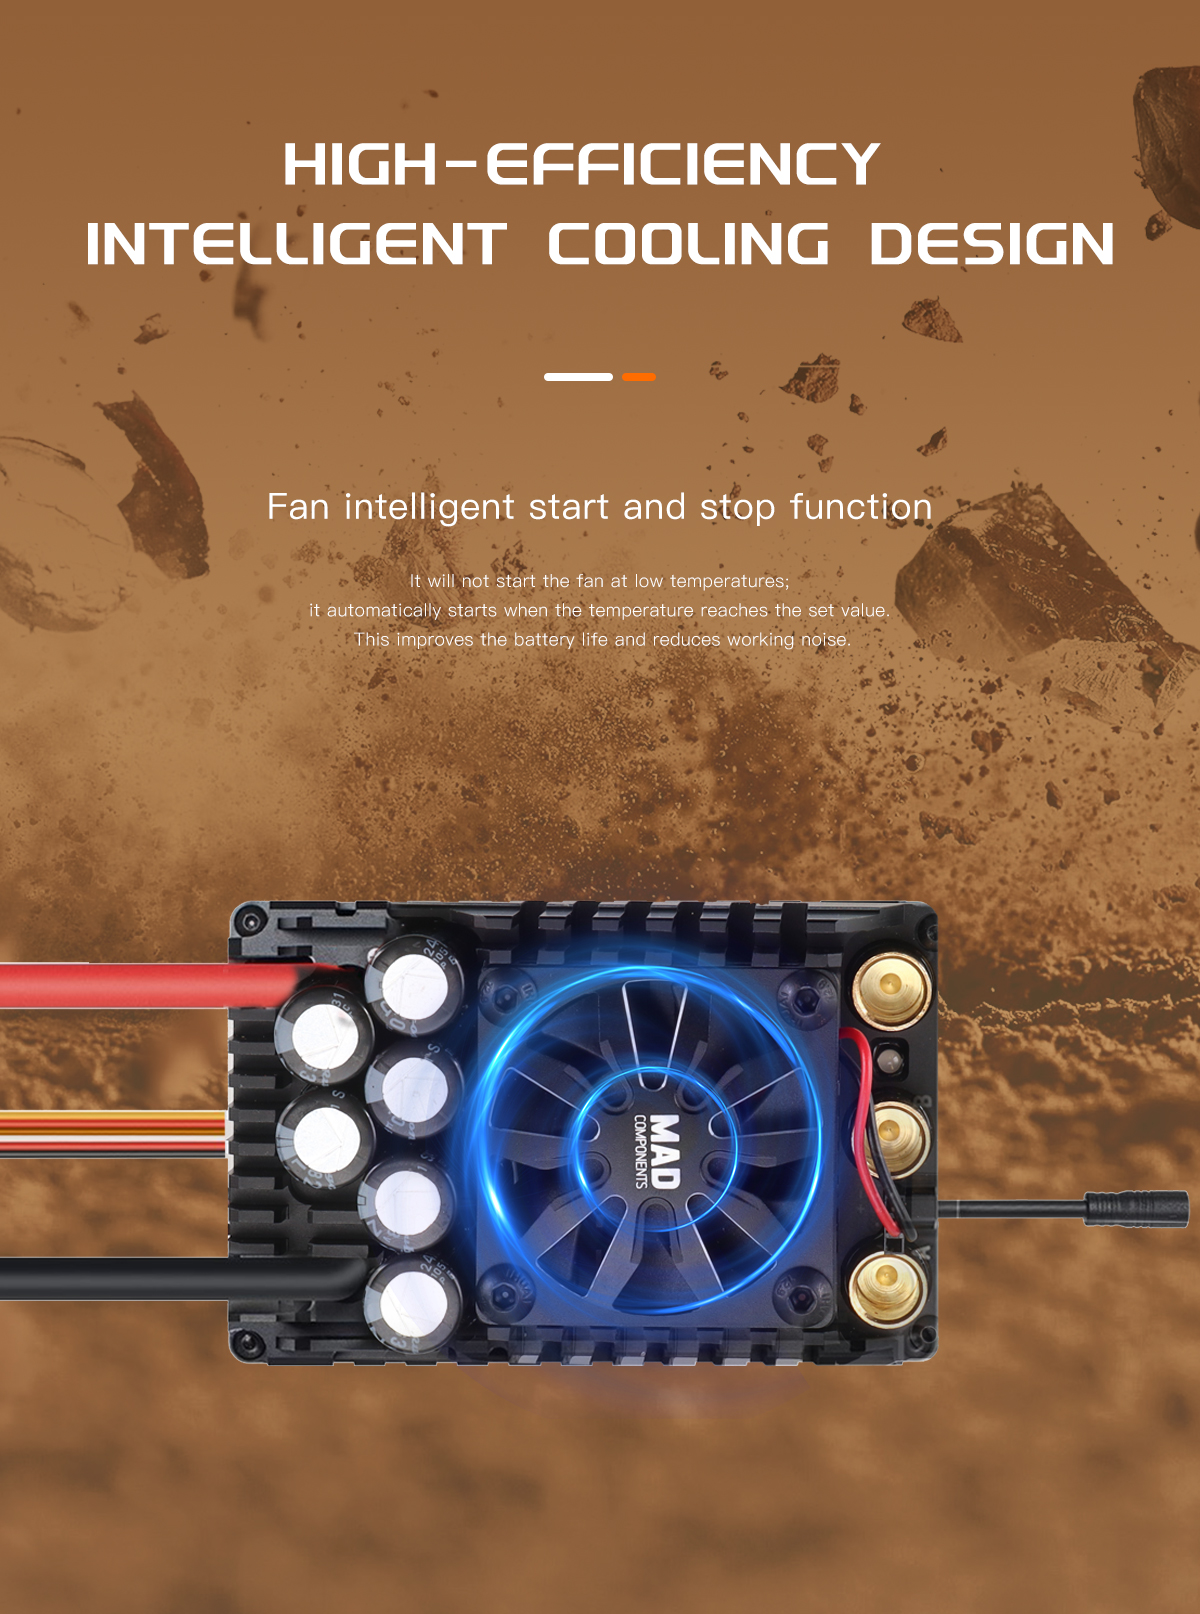
| Fan | Temperature> 55℃, power supply to the fan turns on. Temperature < 50℃,power supply to the fan turns off. When there is a large current abnormality, the controller turns off the fan power supply |
1. The fan powered by BEC 2. When a short-circuit current occurs to the fan, the power will be cut off. Power recovered in 1 second |
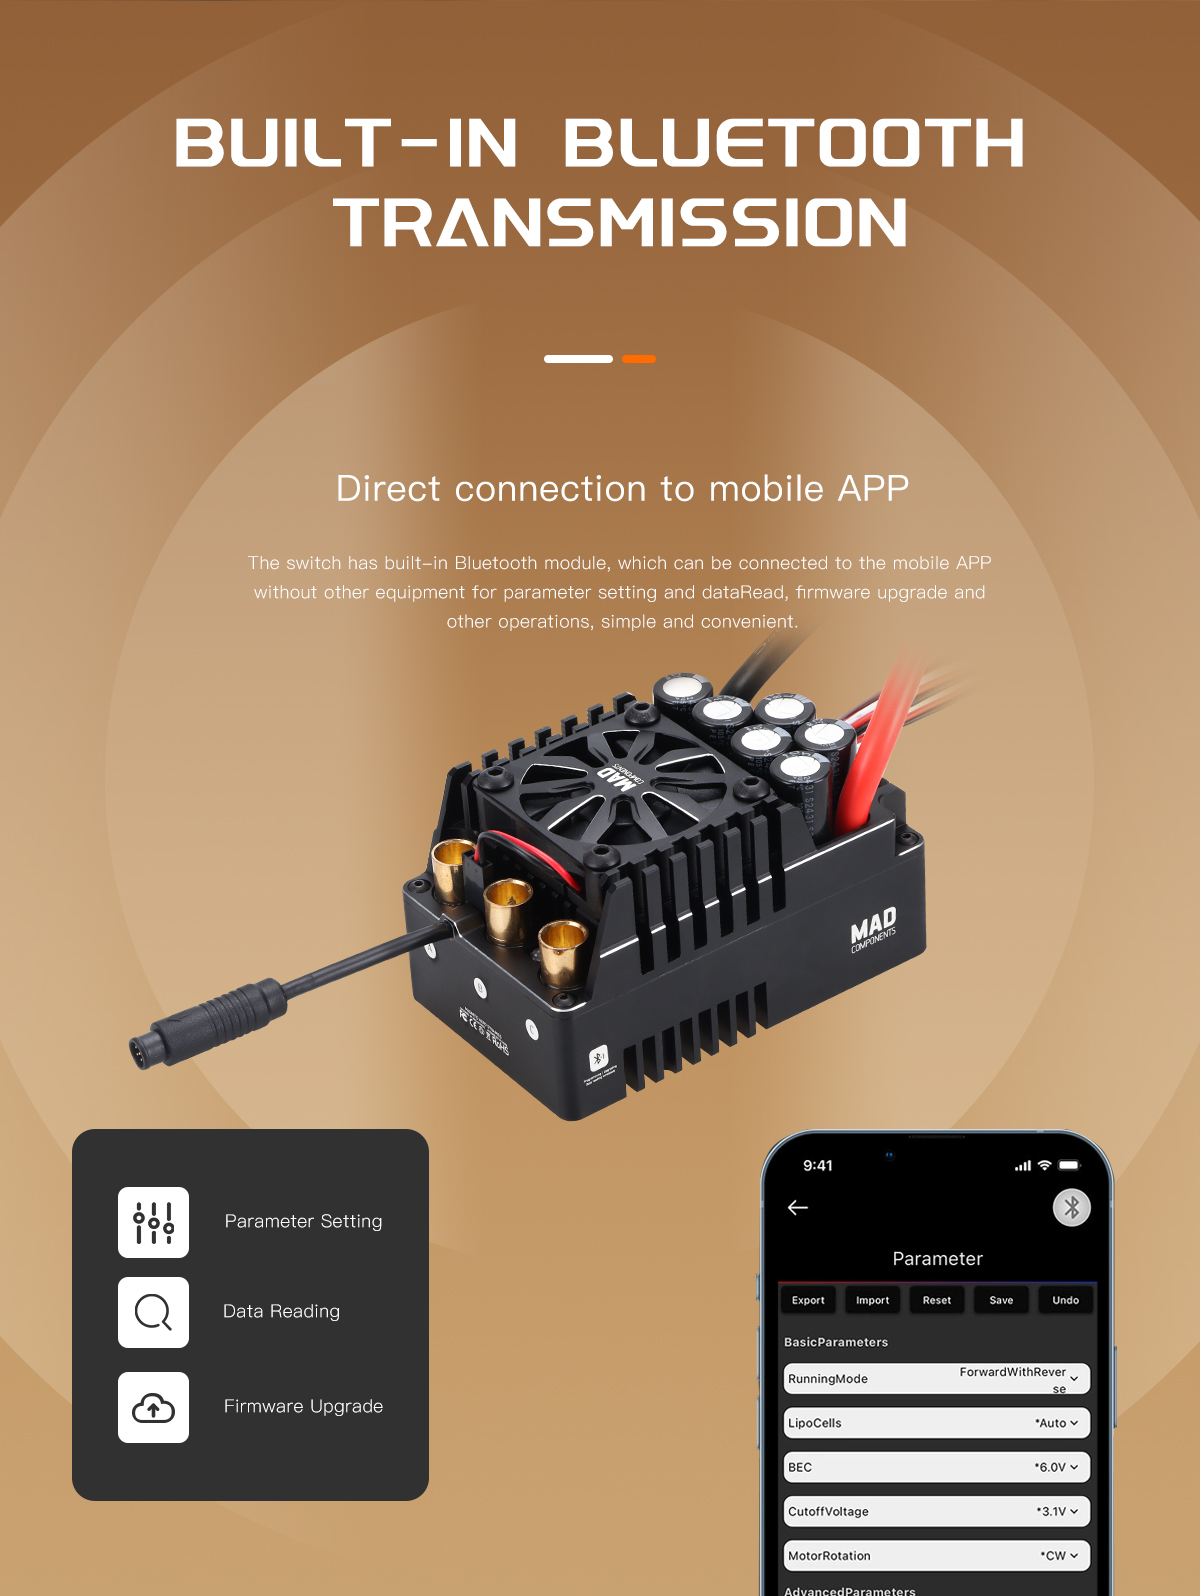
| Bluetooth | 1. All parameters of the ESC can be adjusted by using the mobile APP 2. The ESC firmware can be upgraded by using the mobile APP 3.Motor operation data observation: data log and real-time data. |
|
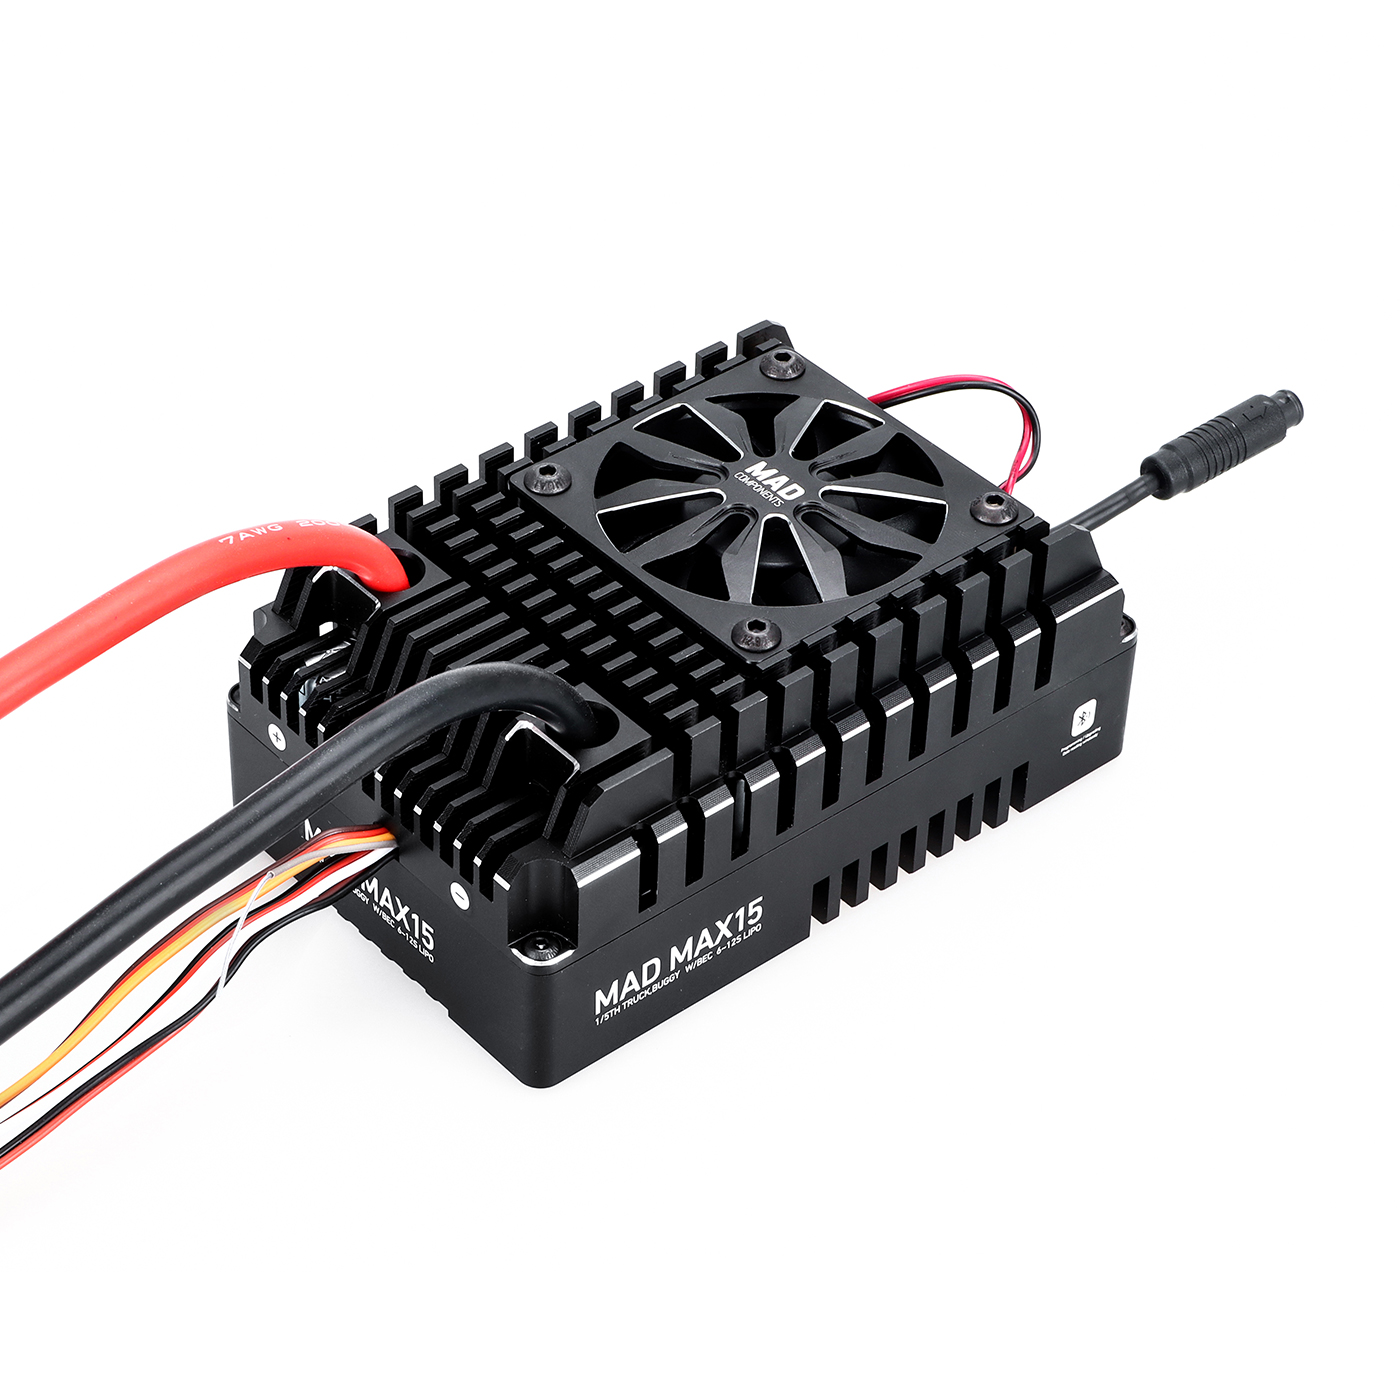
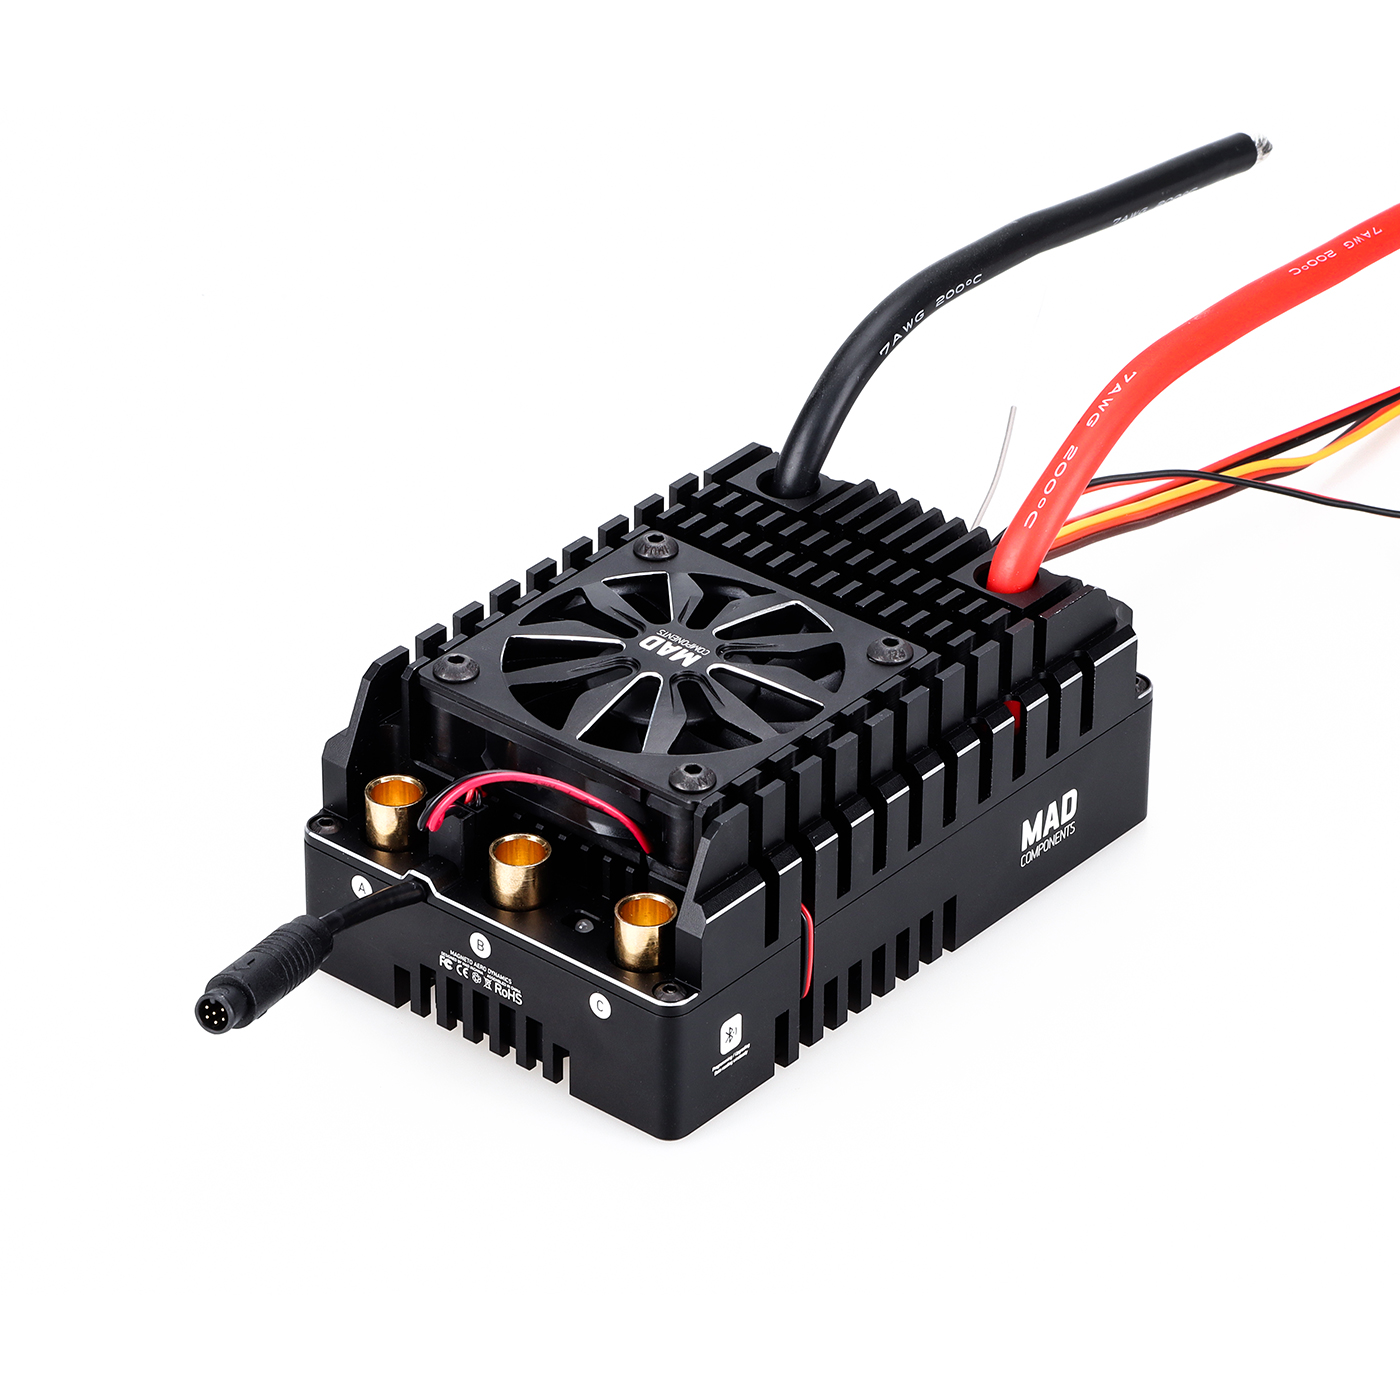
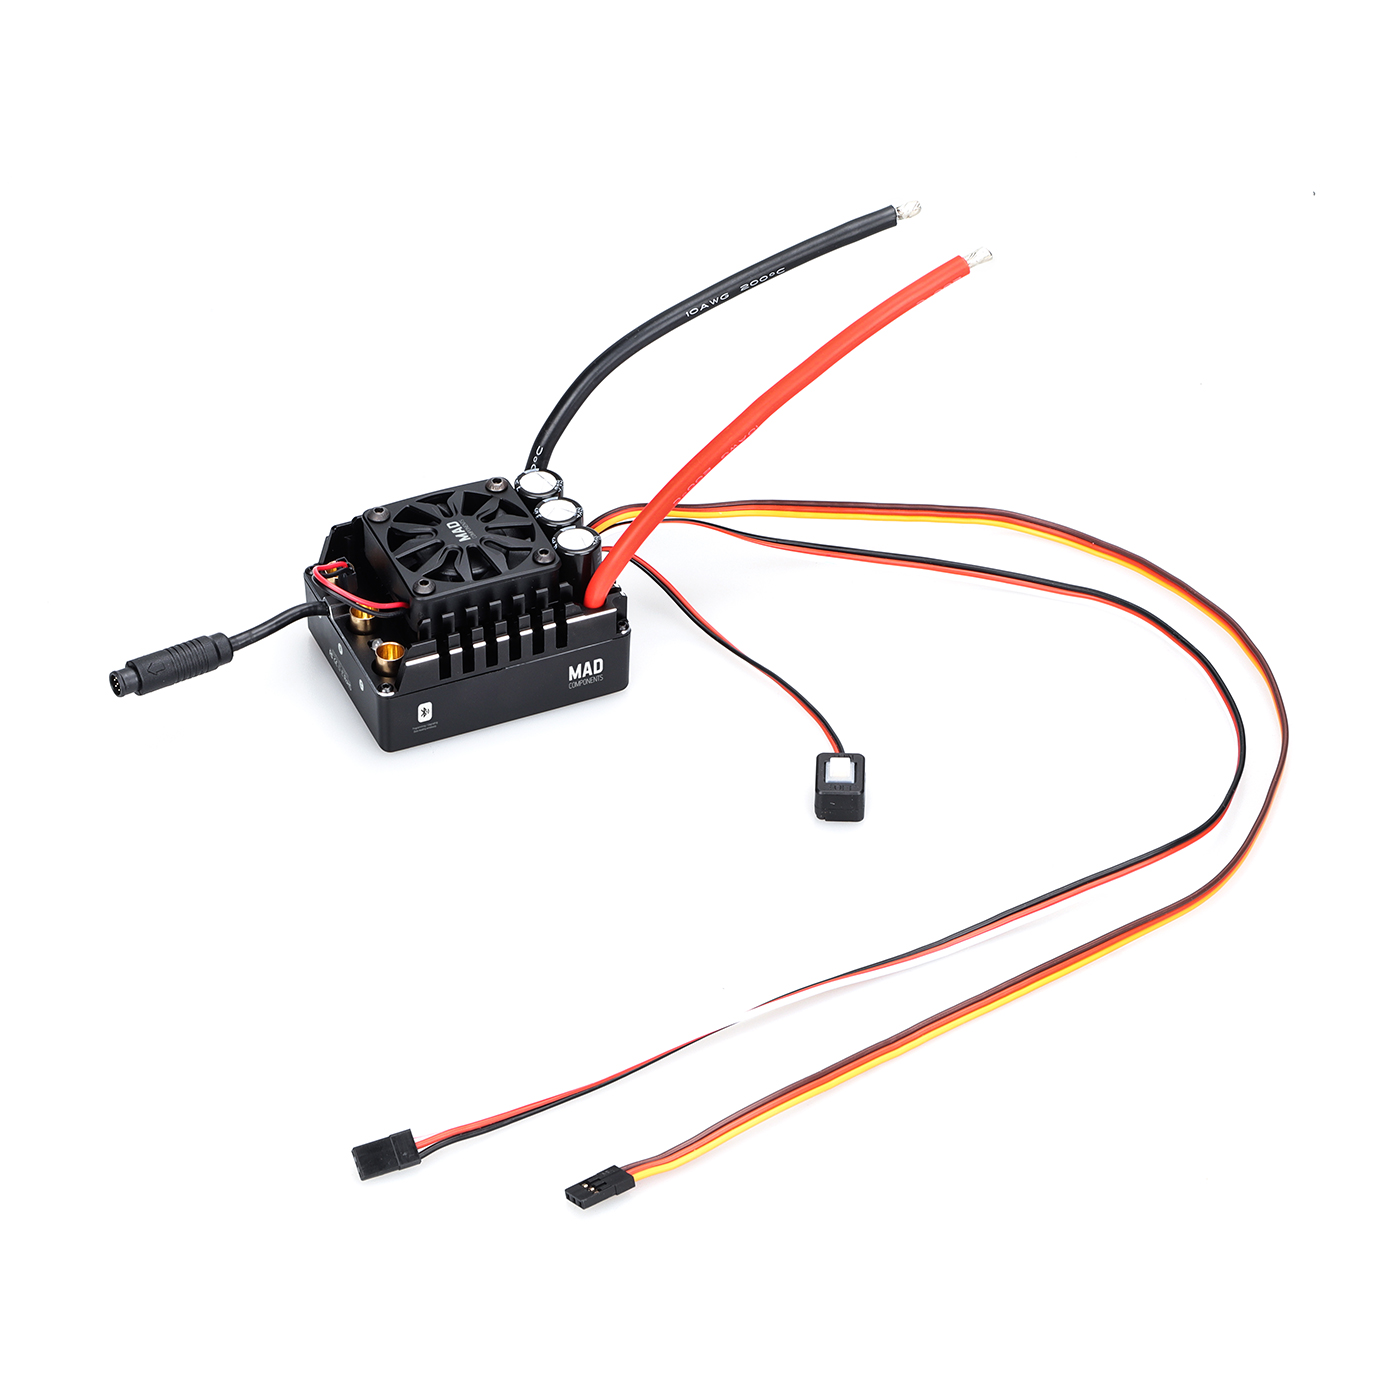
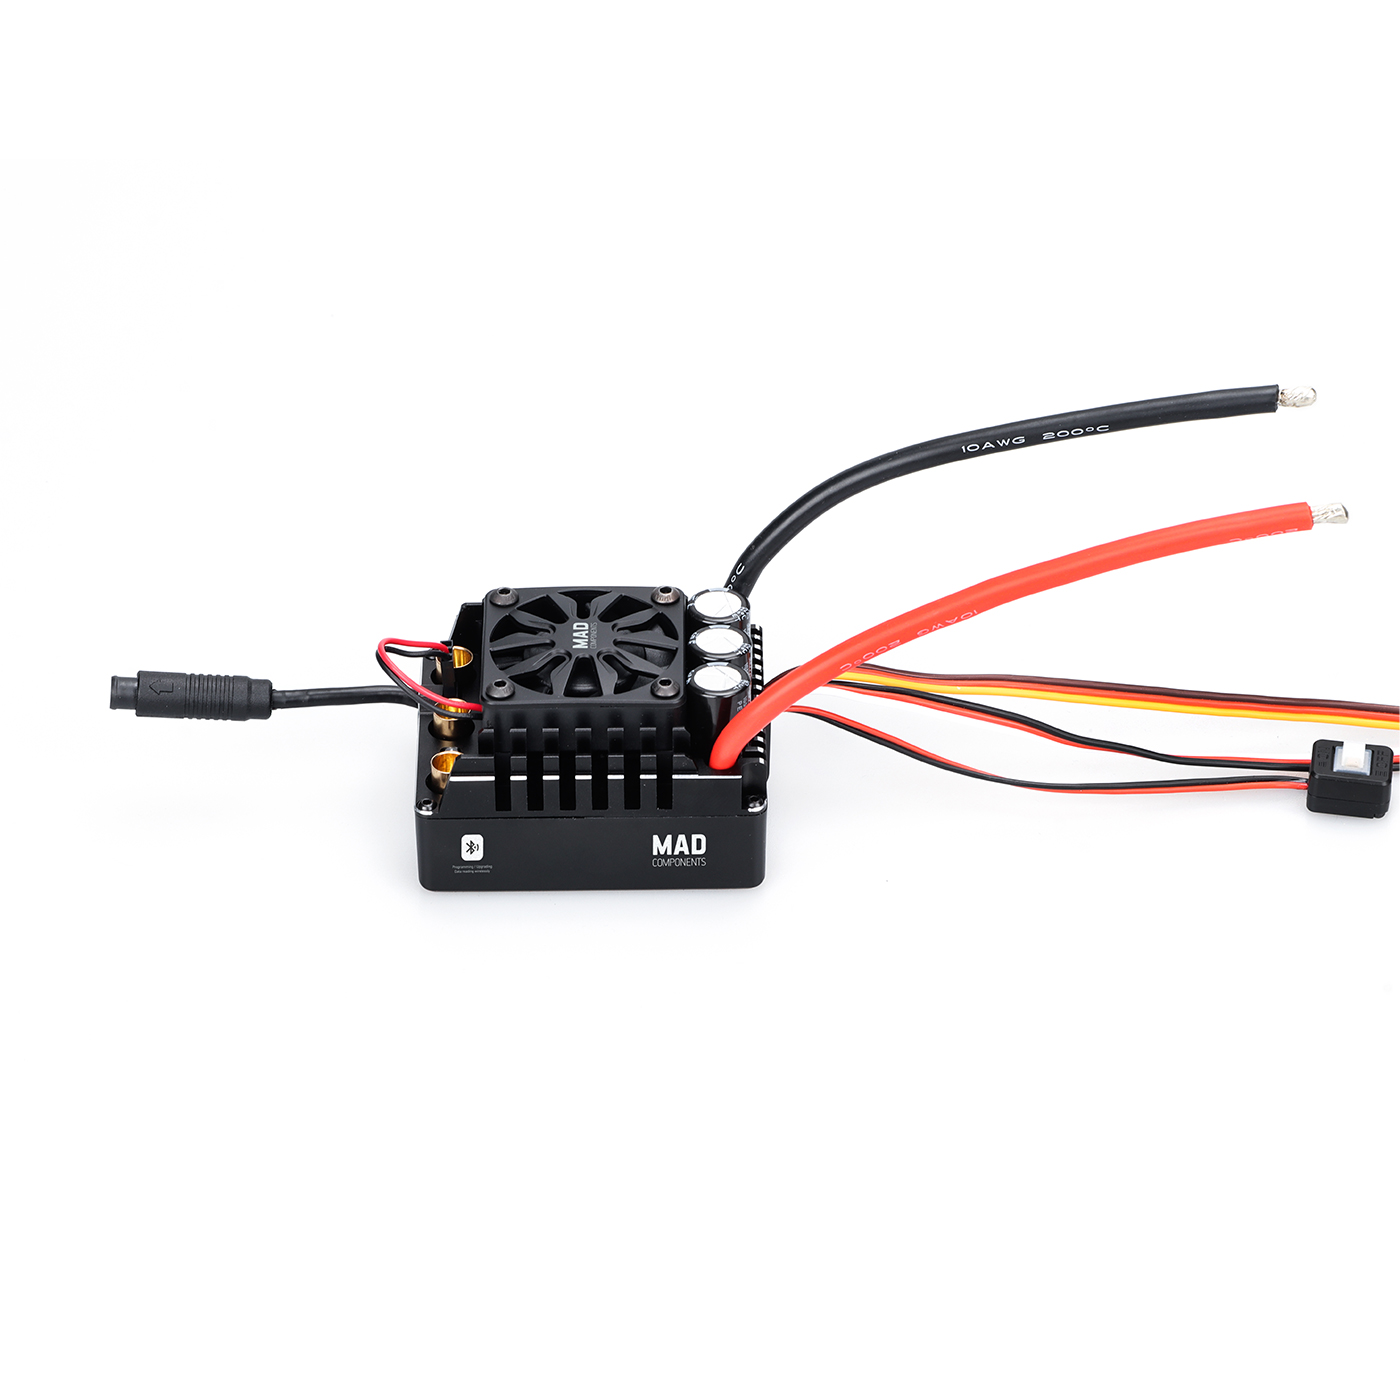
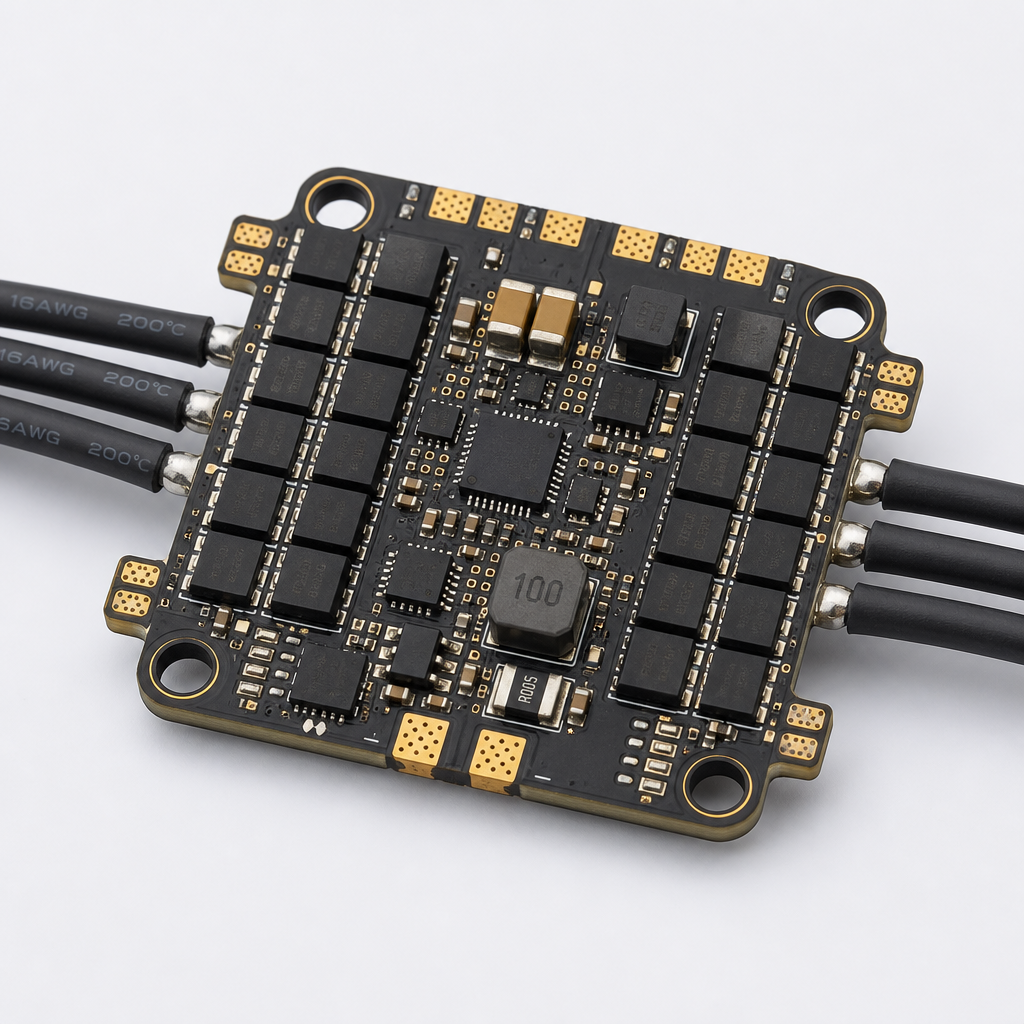
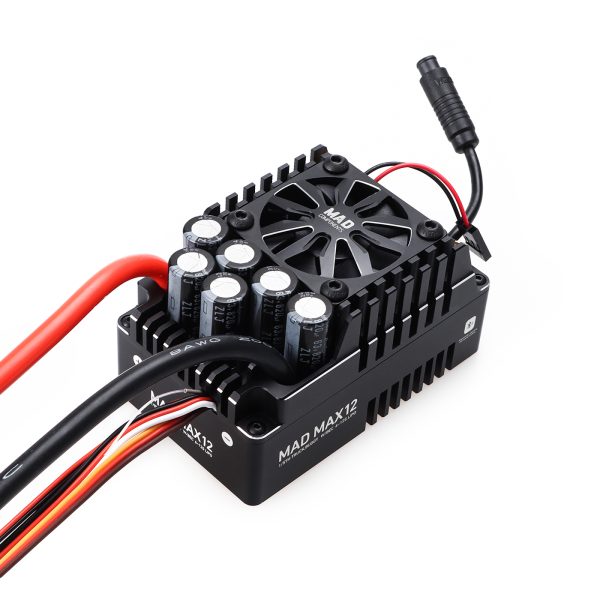
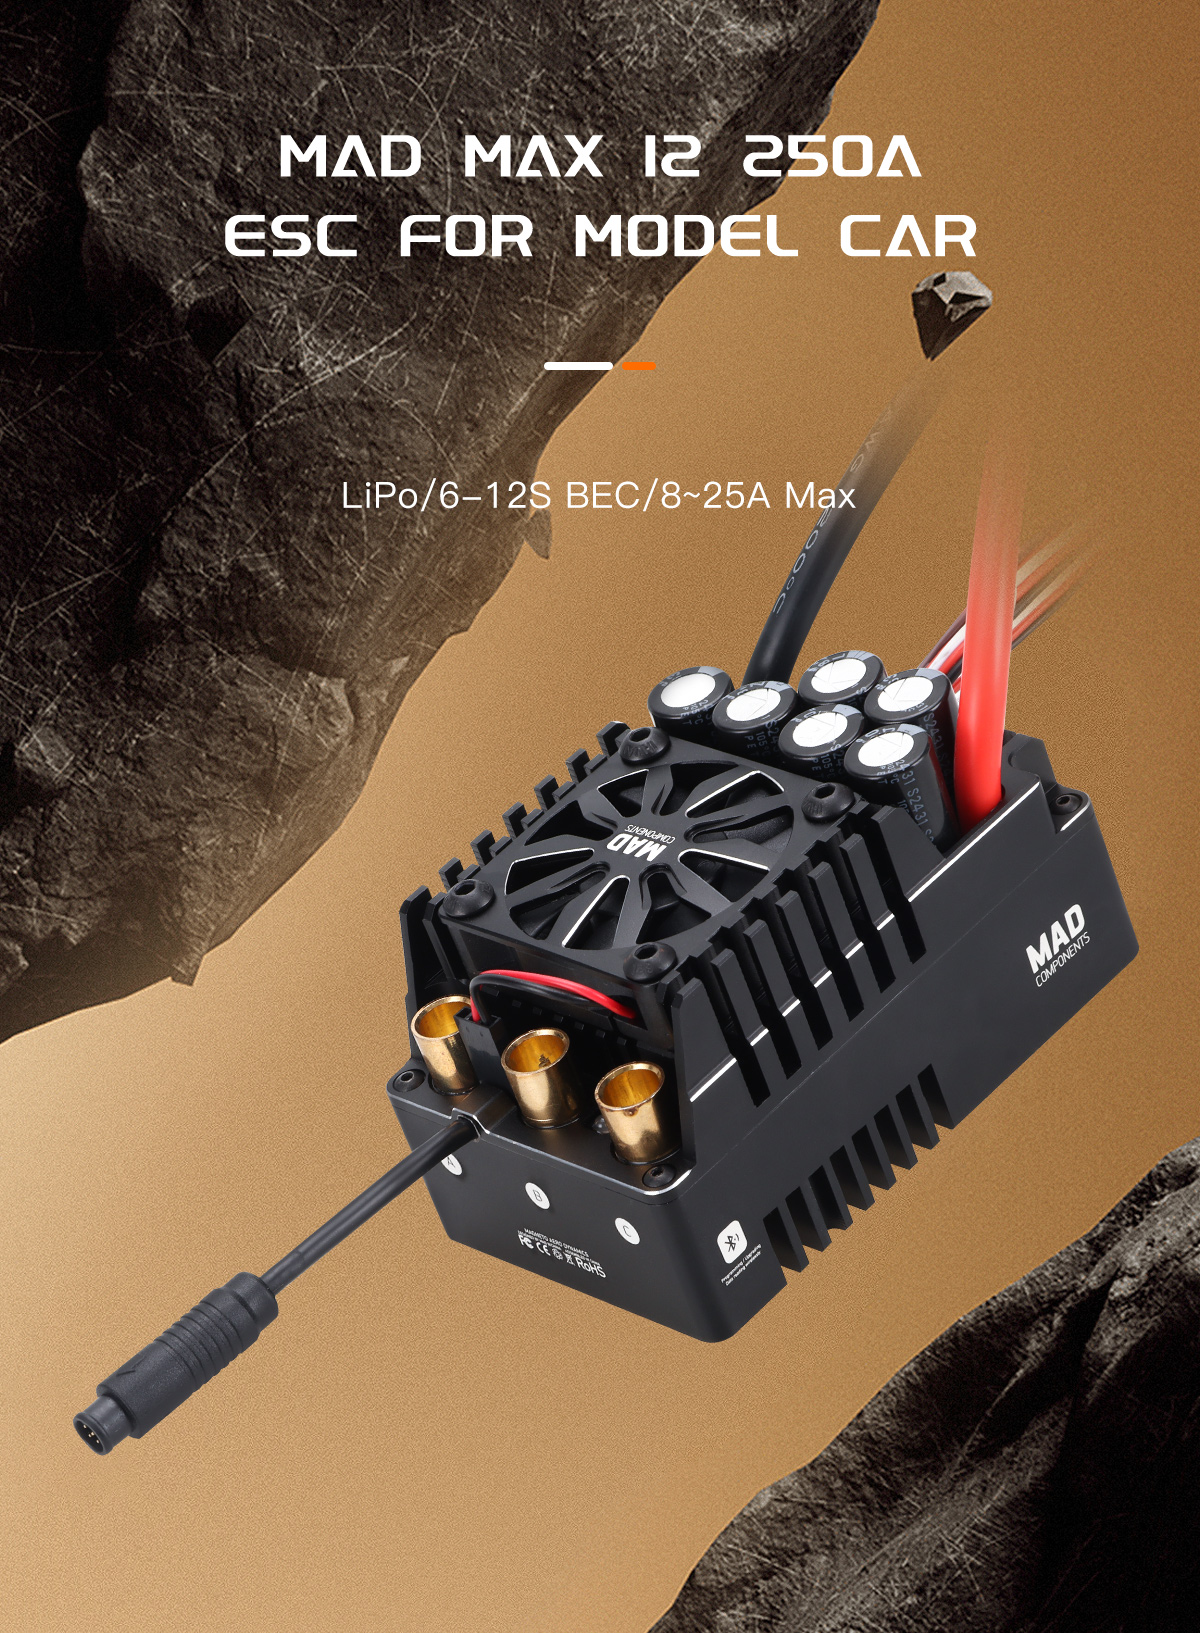
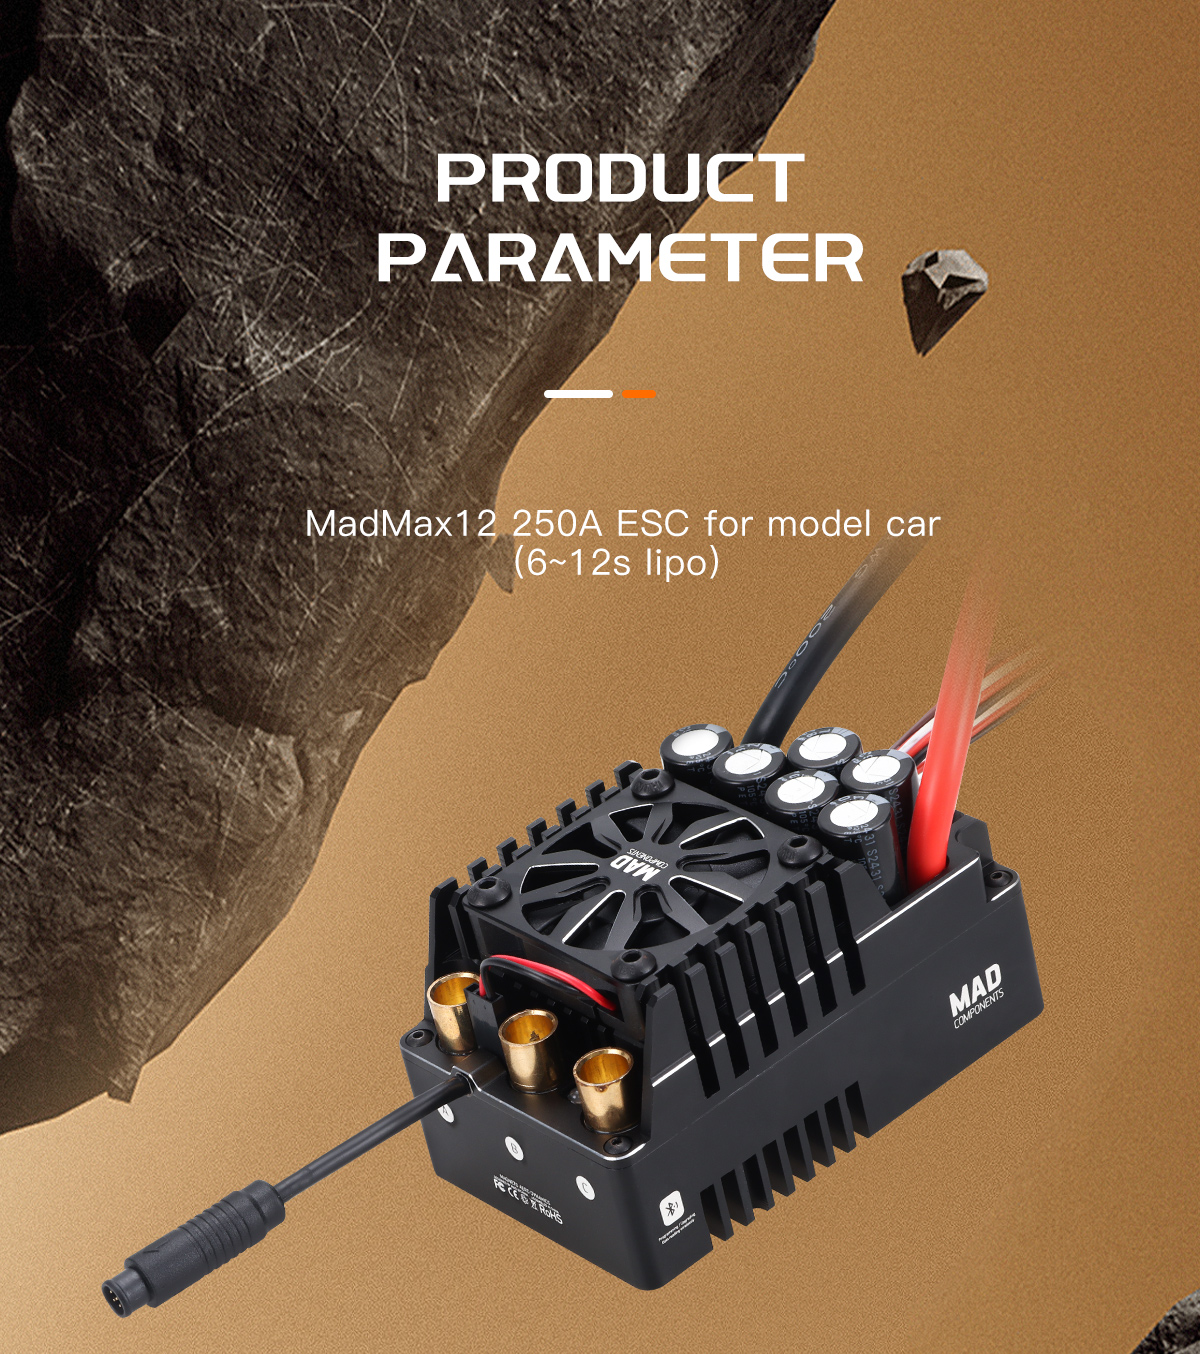
| Dimension | 93.80(L)*59.00(W)*53.60(H)mm / ≈ 470g (with wire) |
Features:
2.1 Meticulously proved commutation scheme, smooth commutation even in noninductive.
2.2 Active freewheeling technology can reduce MOS heating while avoiding excessive current pulses.
2.3 Current limiting in each PWM cycle reduces the impact of pulse current on the motor.
2.4 Intelligent heat dissipation ensures the fan operates silently at low temperatures.
2.5 Built-in Bluetooth connections to mobile APP for hardware management and parameters setting.
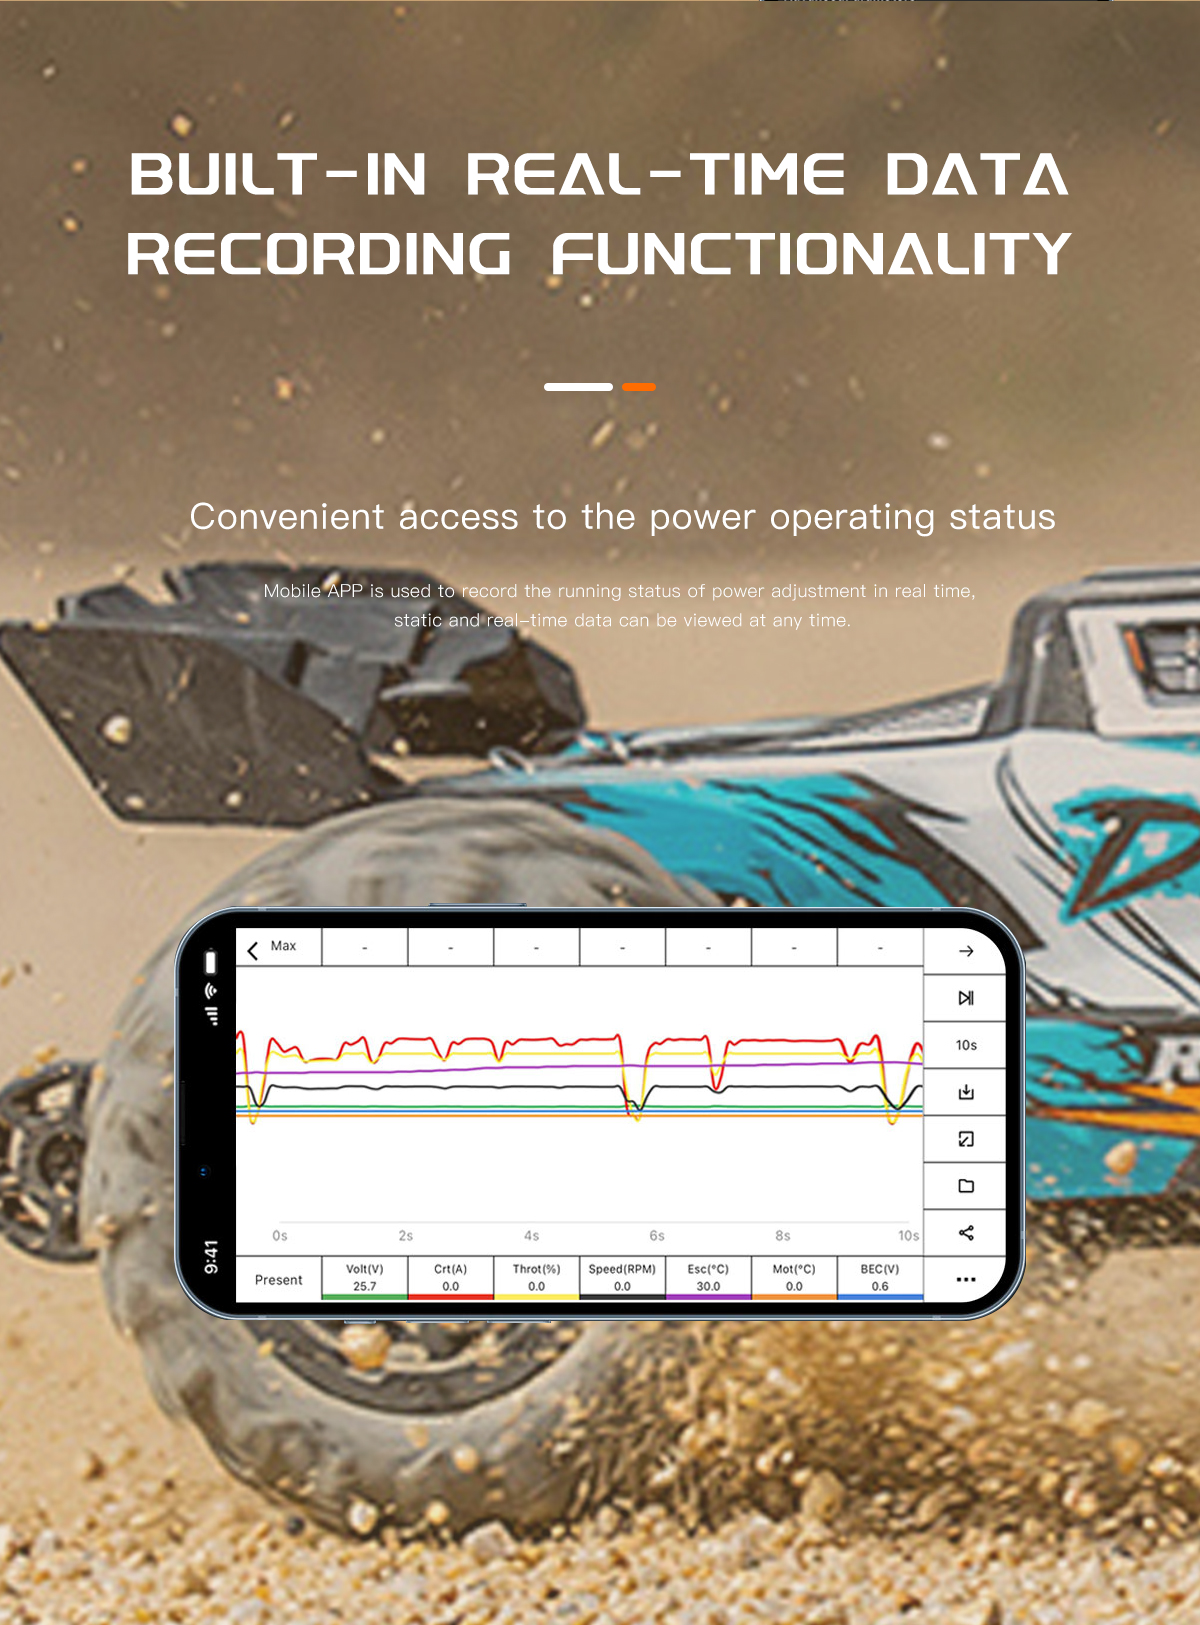
2.6 Mobile APP data observation interface for viewing ESC recording data (static data) and real-time debugging data.
2.7 High-power DC conversion circuit makes BEC a potent loading capacity.
2.8 Full protection: low voltage, over voltage, throttle loss, abnormal braking, over temperature etc.
2.9 Turbo timing available.
2.10 No need to buy additional modules, you have a READY-TO-RUN speed controller.
2.11 Supporting XC BUS protocol, real-time control of ESC and reading of operation data through Bus. It can be used for robot control or other automated programming control.
Connections: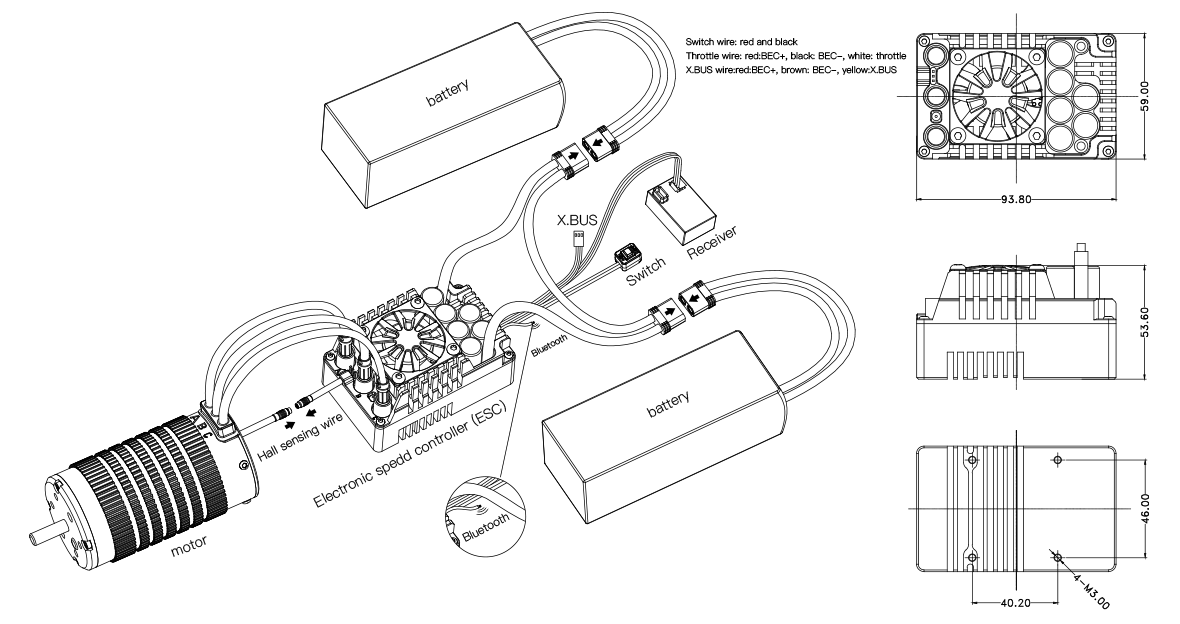
Precautions:
- Please do not connect the ESC input wires DC+ and DC- in reverse. Reverse connection may damage the ESC
If the ESC is damaged in this case, the relevant warranty service will not be provided. - If a Hall sensor is used, be sure to check the motor phase wires and Hall wiring.
- For motors without temperature sensors, long-term high-power operation may cause burnout.
- The mechanical structure of some motors cannot support high speed. If the speed is forcibly increased, the motor may be damaged.
- If not used for more than 1 hour, it is recommended to unplug the power wires of the ESC.
- If there are any modifications to the connection line, check the circuit carefully before putting in use. It is recommended to open the throttle slowly and confirm that there are no errors before advancing it normally
Start The Process:
Steps:
1. Check whether the circuit is open, short circuit or in poor contact.
2. Check whether the motor is stuck.
3. Plug in the power cable.
4. Turn on the power button.
When you hear the battery prompt tone (described in the “Normal Startup” prompt in the light/sound prompt section), the startup is normal. If the throttle is normal, you can
perform the throttle operation normally.
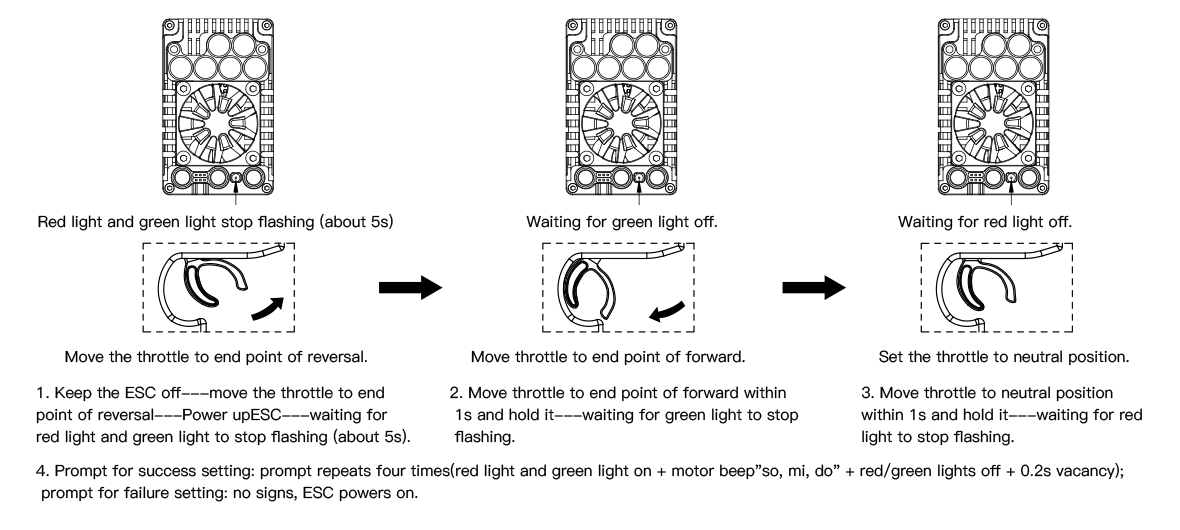
Set The Throttle Range:
Bluetooth:
The naming rule of Bluetooth name is “approximate model” + “-” + “ESC code ID”, for example, where “XC_E3-1C89”, XC_E3 is the approximate model, and “1C-89” is the hexadecimal
code ID of the ESC. Even if the user sets the Bluetooth name by himself, the ESC code ID is still retained to avoid two devices with the same name.
Configurable items:
| Seq | Item | Description | Default | |||
| 1 | Running mode | Forward with brake | Forward&Reverse and Brake | Forward with reverse | Forward&Reverse and Brake | |
| 2 | LipoCells | Auto | 6 ~ 12S | Auto | ||
| 3 | BEC voltage | 6.0V | 7.4V | 8.4V | 6V | |
| 4 | Cutoff Voltage | Disabled | 2.9~3.6V | 3.2V | ||
| 5 | Motor Rotation | Forward | Reverse | Forward | ||
| 6 | Max.Brake Force | 0~100% | 60% | |||
| 7 | Max.Reverse Force | 0~100% | 25% | |||
| 8 | Punch | 0~12 level | 6 level | |||
| 9 | Drag Brake Force | 0~100% | 0% | |||
| 10 | Turbo Timing | 0~26 degree | 26 degree | |||
| 11 | Turbo Delay | 0~1S | 1s | |||
| 12 | Initial PWM | 1~10% | 5% | |||
| 13 | Motor Pole Pairs | 2~15% | 10% | |||
| 14 | Motor Pole Pairs | 1~64 | 2 | |||
| 15 | Communication BUS | X.BUS Protocol | X.BUS Protocol | |||
| 16 | X.BUS-ID | 0~15 | 0 | |||
1. Running Mode:
Option 1: Forward with brake
The vehicle can only move forward and has brake function. This is also commonly acceptable in races.
Option 2: Forward/Reverse and Brake
This option is known to be the “training” mode with “Forward/Reverse with Brake” function. The vehicle only brakes at the first time you push the throttle trigger to the
reverse/brake zone. If the motor stops when the throttle trigger return to the neutral zone and then re-push the trigger toreverse zone, the vehicle will reverse.if the motor
does not completely stop, then your vehicle won’t reverse but still brake, and you need to return the throttle trigger to the neutral zone and push it to reverse zone again.
This method is for preventing vehicle from being accidentally reversed.
Option 3: Forward and Reverse
When the throttle trigger is pushed from neutral to reverse point, the motor reverses. This mode is generally used in special vehicles.
2. Lipo Cells:
Set the correct value according to the actual number of Lipo batteries used. The default is automatically calculated.
3. Low Voltage Cut-Off:
This function is mainly to prevent excessive discharge of lithium batteries causing damage. The ESC monitors the battery voltage at all times, and once the voltage falls
below the set threshold, the power output is reduced and the power output is completely cut off after a few seconds,and generates a 10% braking force. For NIMH
batteries, it is recommended to set this parameter to “Disabled”.
4. Motor Rotation:
Setting the rotation of the motor. Due to some differences in the drivetrains on different car kits, it is possible that the car will go in the opposite direction upon full throttle.
In the event that this happens, you can set the“motor rotation direction” to the opposite direction; “CW” or “CCW”.
5. BEC Voltage:
BEC voltage supports 6V/7.4V/8.4V. Generally, 6.0V is suitable for standard servos, while 7.4V/8.4V is suitable for high-voltage servos. Please set according to the servo specifications.
WARNING! Do not set the BEC voltage above the maximum operating voltage of the servo, as this may damage the servo or even the ESC.
6. Max. Brake Force:
This ESC provides proportional braking function; the braking effect is decided by the position of the throttle trigger. It sets the percentage of available brakingpower when full brake is
applied. Large amount will shorten the braking time but it may damage your pinion and spur gear.
7. Max. Reverse Force:
Refers to the reversing speed. Selecting different parameter values can produce different reversing speed. It is recommended to use a smaller reversing speed to avoid
errors caused by reversing too fast.
8. Punch:
Set in 1-9 stages, the higher the set value, the faster the acceleration. Kindly consider according to the site, tire grip characteristics vehicleconfiguration etc. An aggressive
setting may cause tire slippage, excessive starting current and adverse effects on the electronics performance adversely.
9. Drag Brake Force:
Refers to the brake force generated by the motor when the throttle trigger returns to neutral position. Choose the appropriate value according to the type of vehicle, configuration, site, etc.
10. Turbo Timing:
The Turbo timing can additionally increase the motor rpm.It will initiate at full throttle. It is usually used on a long straight road to release the maximum power of the motor. The higher
this value is, the more the rpm of the motor will increase, and the greater the running current will be, the higher the temperature of the motor and esc. Therefore, please set this value
reasonably.
11. Turbo delay:
It refers to the duration of continuous full throttle required to trigger Turbo. When the full throttle time reaches this set value, Turbo can be triggered to turn on.
12. Initial PWM:
Also called minimum starting force, it refers to the starting force acting on the motor at the initial position of the throttle. The required starting force can be set according to the tires and
site grip. If the venue is too slippery, set a smaller starting force to avoid slipping.
13. Motor Pole Pairs:
For setting pole pairs. Motor Rotation speed=Electrical Speed / Pole Pairs, To get the precise mechanical rotational speed, the pole pairs must be set correctly.
14. Communication BUS:
FUTABA_T4PM & FS sensor-to-sensor data transmission:These two modes of data transmission are available, voltage, temperature and motor speed etc can be viewed
on RC. XC. BUS Controls the throttle of ESC in the form of programming, or dynamically adjusts the motion parameters, reads the operation parameters of ESC, etc. It can be
used in automation or robot situations. For specific content of the protocol, please refer to the XC.BUS Control Protocol.
15. XC.BUS-ID:
This item will take effect if XC.BUS is selected in item 14. XC.BUS can control up to 16 ESCs.
Recover factory parameters:
How to restore Bluetooth to factory settings:
If the Bluetooth password is lost or if you need to forcibly enter Boot, please follow the instruction:
Step 1: Connect ESC wire(the white wire) to BEC+(red wire)
Step 2: Turn on ESC
Step 3: Disconnect from BEC when green light off and red light on
Step4. Remove short circuiting
When boot activated, the status of Bluetooth will restore to factory value(password will be restored to 1234, and the name will be restored to the factory state), then restart ESC,
If there is a hardware error, Boot can be activated in this way to upgrade hardware.
How to restore parameters to factory settings:
If you want to restore the parameters to factory settings, just click the default button on the APP parameter page.
LED status & beep instructions:
| Item | Type description | Light cue | Sound cue | Remark | |
| Basic information |
Throttle not zeroed | Red light flashes quickly | Long tone “beep” | Red light flashes quickly | |
| Throttle signal lost | Red light flashes slowly | Long tone “beep” | In cycle of 2s | ||
| Voltage detection | Low voltage protection | (Redx1 Greenx2) … | Long tone “beep”x1, Short tone “beep”x2 |
Check the input voltage or setting of number of cells if no “beep” before MOSFET detecting. |
|
| Over voltage protection | (Redx1 Greenx3) … | Nil | Voltage is too high, check whether the voltage is over the withstand value of ESC |
||
| The MOS temperature is too high, operating temp. > 125 ℃ / startup temp. > 110 ℃ |
(Redx1 Greenx4) … | Long tone beepx1, short tone beepx4 |
The temperature of MOS is too high. ESC can resume normal operation when the temperature drops below 100 degrees Celsius |
||
| The capacitor temperature is too high, operating temp. > 105 ℃ / startup temp. > 100 ℃ |
(Redx1 Greenx5) … | Long tone beepx1, short tone beepx5 |
The temperature of capacitor is too high. ESC can resume normal operation when the temperature drops below 100 degrees Celsius |
||
| Throttle parameters | Abnormal throttle parameters | (Redx1 Greenx7) … | Long tone beepx1, short tone beepx7 |
If there is still an abnormal promp when positioming throttle to neutral point, throttle calibration process needs to be initiated. |
|
| Hall sensing abnormality | Hall output logic abnormality | (Redx1 Greenx8) … | Long tone beepx1, short tone beepx8 |
Re-plug Hall wire. If the abnormality persists, it may be a problem with the internal Hall of the motor, and the Hall wire needs to be unplugged. |
|
| Throttle calibration prompt | Calibrate low range | (Red Green) … | Nil | If the calibration process is irregular or unsuccessful, the ESC will exit the calibration process and enter the normal Startup process. |
|
| Calibrate high range | (Green) … | ||||
| Calibrate neutral throttle | (Red) … | ||||
| Calibration success | (Red Green) x4 | (so-mi-do) x4 | |||
| Normal operation | All normal and no action to throttle | (Green) … | Nil | ||
| Throttle operation | Normal | The greater the accelerator, the faster the green light flashes |
|||
| Turbo timing is on | Green light remains on | ||||
| Braking | Red light is on | Nil | Red light off when release brake | ||
| Boot | Entering boot forcibly | Nil | Follow the process of Bluettoth factory reset | ||
| Boot in progress | Green light: On 2s&Off 2s | Nil | The duration of the red light on = the time of the flash operation |
||
| Red light remains flashing | |||||
| Normal startup | Prompt for the number of battery cells after normal startup |
Quinary prompt light signal, long tone with red light on, short tone with green light on |
do, mi, so + quinary prompt sound |
do, mi, so: prefix of quinary number Quinary definition Long tone = 5 cells, short tone = 1 cell Example: 8-cell lithium battery prompt sound do, ri, mi + long tone x1 + short tone x3 |
|
| Fault warning | MOS abnormality self-test | MOS open circuit | (Redx2) … | Nil | Unplug motor wire. If there are still abnormalities, ESC needs to be sent for inspection |
| MOS short circuit | (Redx2 Greenx1) … | Nil | |||
| Abnormal sampling circuit of current | (Redx2 Greenx2) … | Nil | |||
*Notes:
1. Red light matches long time. Green light matches short tone.
2. For saving power, all “beeps” last for 5mins; if all faults are recovered, it takes effect again in next 5 mins.
3. Ellipsis”…” in light cue represents the repetition of previous action.